Next
Papers near this one.
Walkthroughs
 5:27
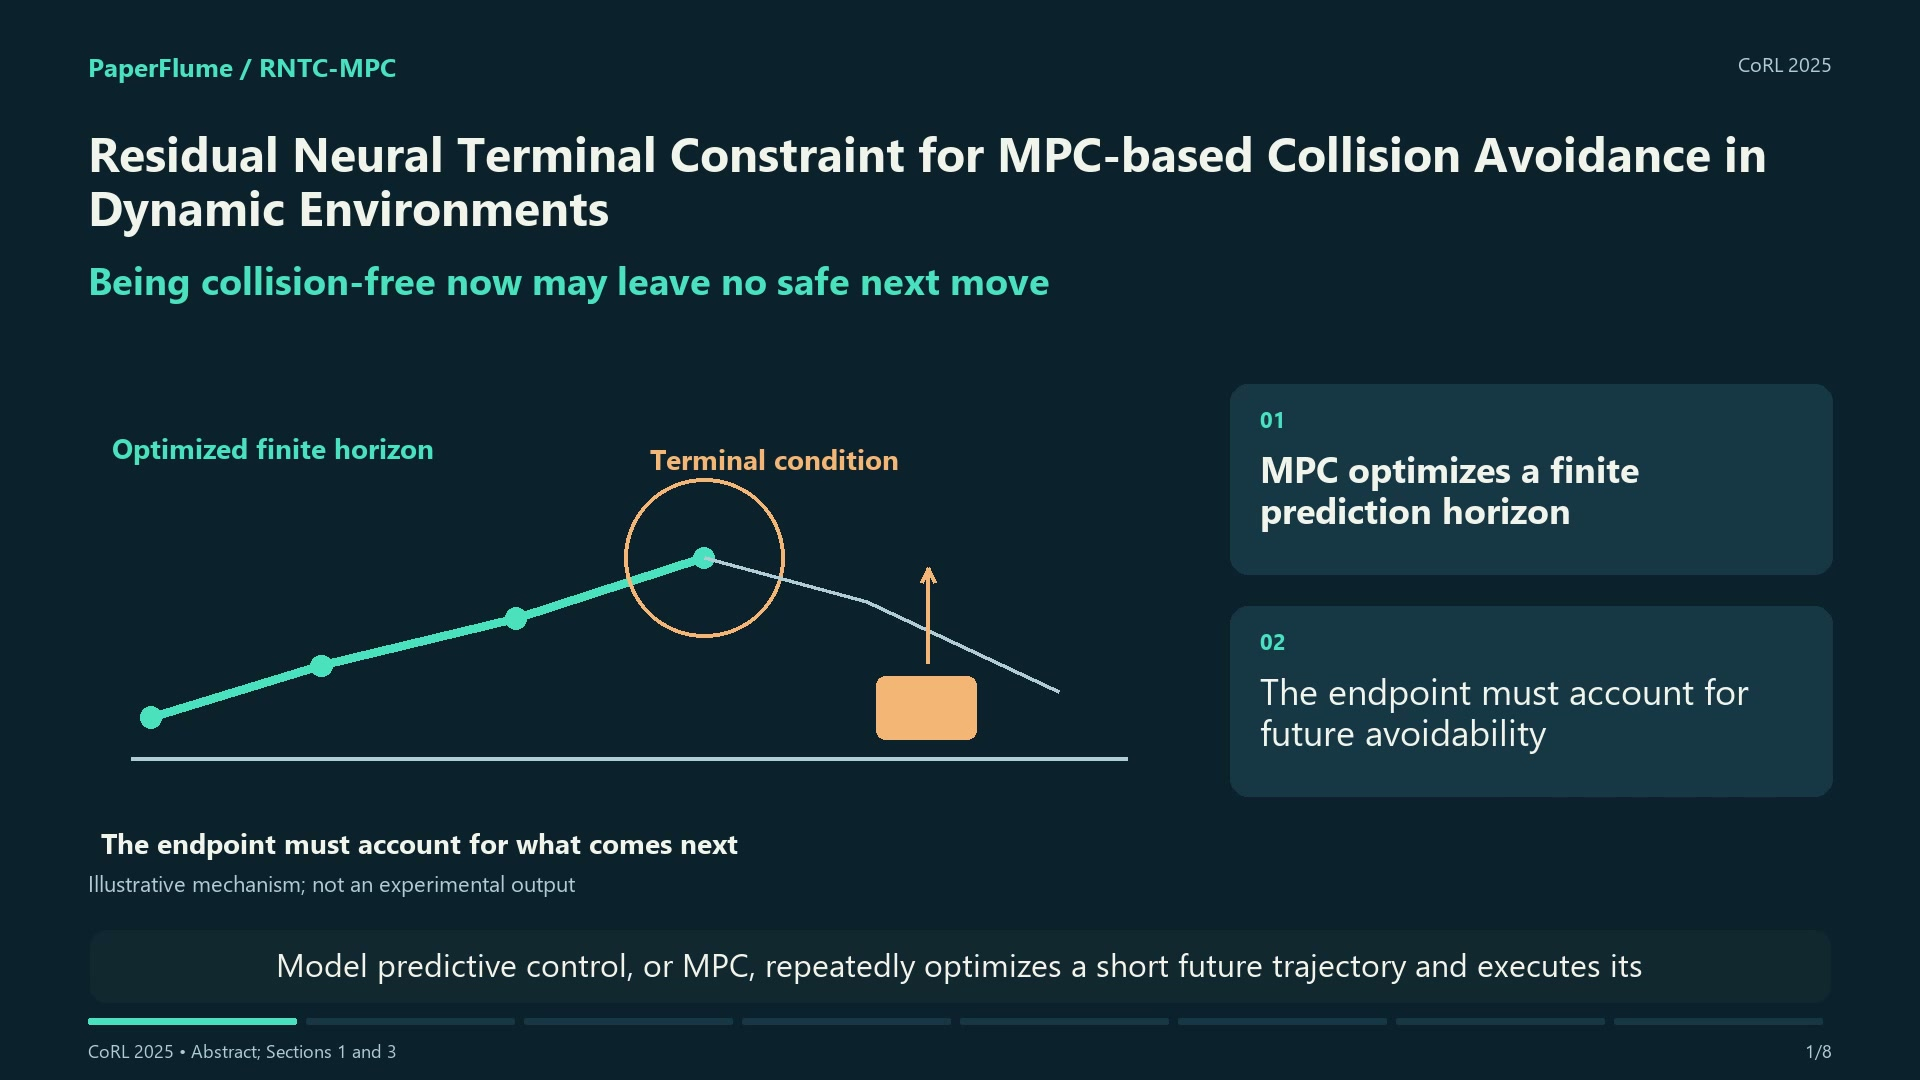
Residual Neural Terminal Constraint for MPC-based Collision Avoidance in Dynamic Environments
shares Model predictive control 6:42
Safety Beyond the Training Data: Robust Out-of-Distribution MPC via Conformalized System Level Synthesis
shares Model predictive control 7:06
Online Adaptive Probabilistic Safety Certificate with Language Guidance
shares Model predictive controlShort cuts
 0:48
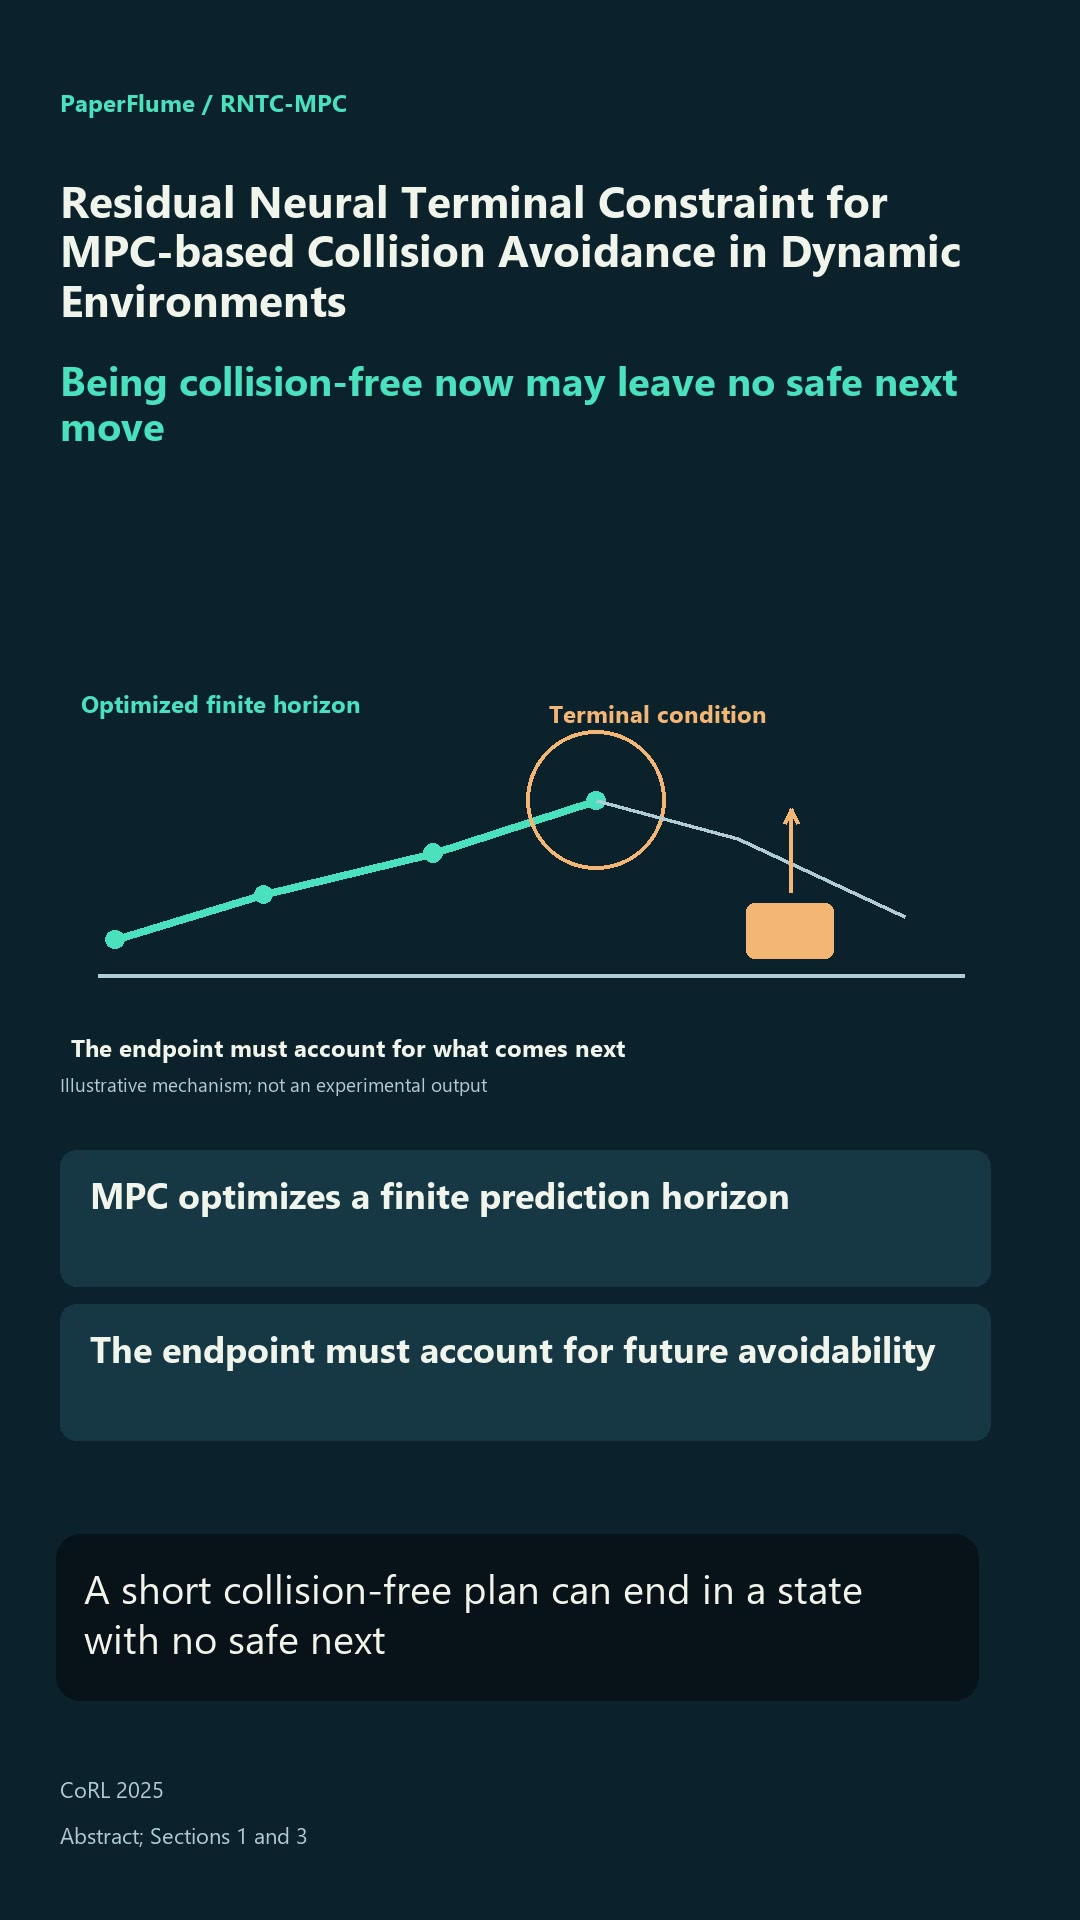
Residual Neural Terminal Constraint for MPC-based Collision Avoidance in Dynamic Environments
shares Model predictive control 0:51
Safety Beyond the Training Data: Robust Out-of-Distribution MPC via Conformalized System Level Synthesis
shares Model predictive control 0:52