Next
Papers near this one.
Walkthroughs
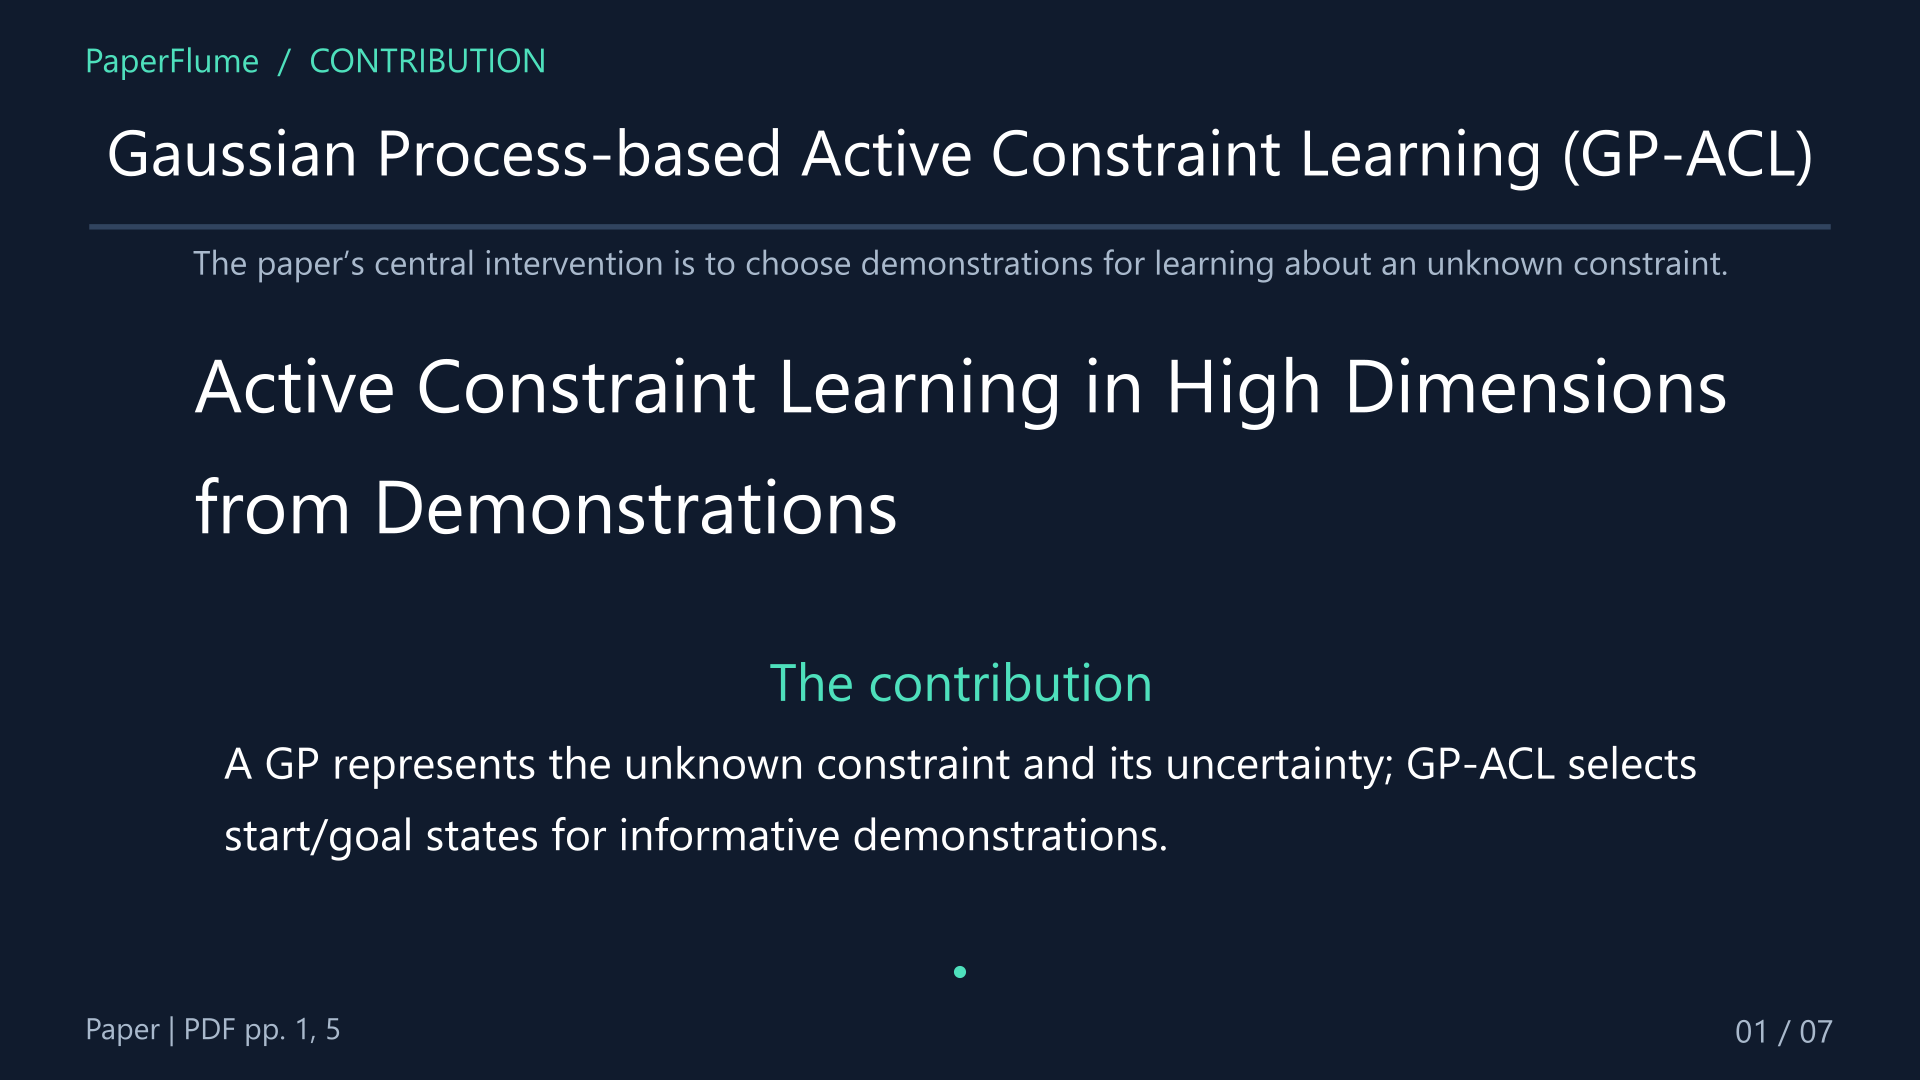 6:37
Active Constraint Learning in High Dimensions from Demonstrations
shares Trajectory optimisation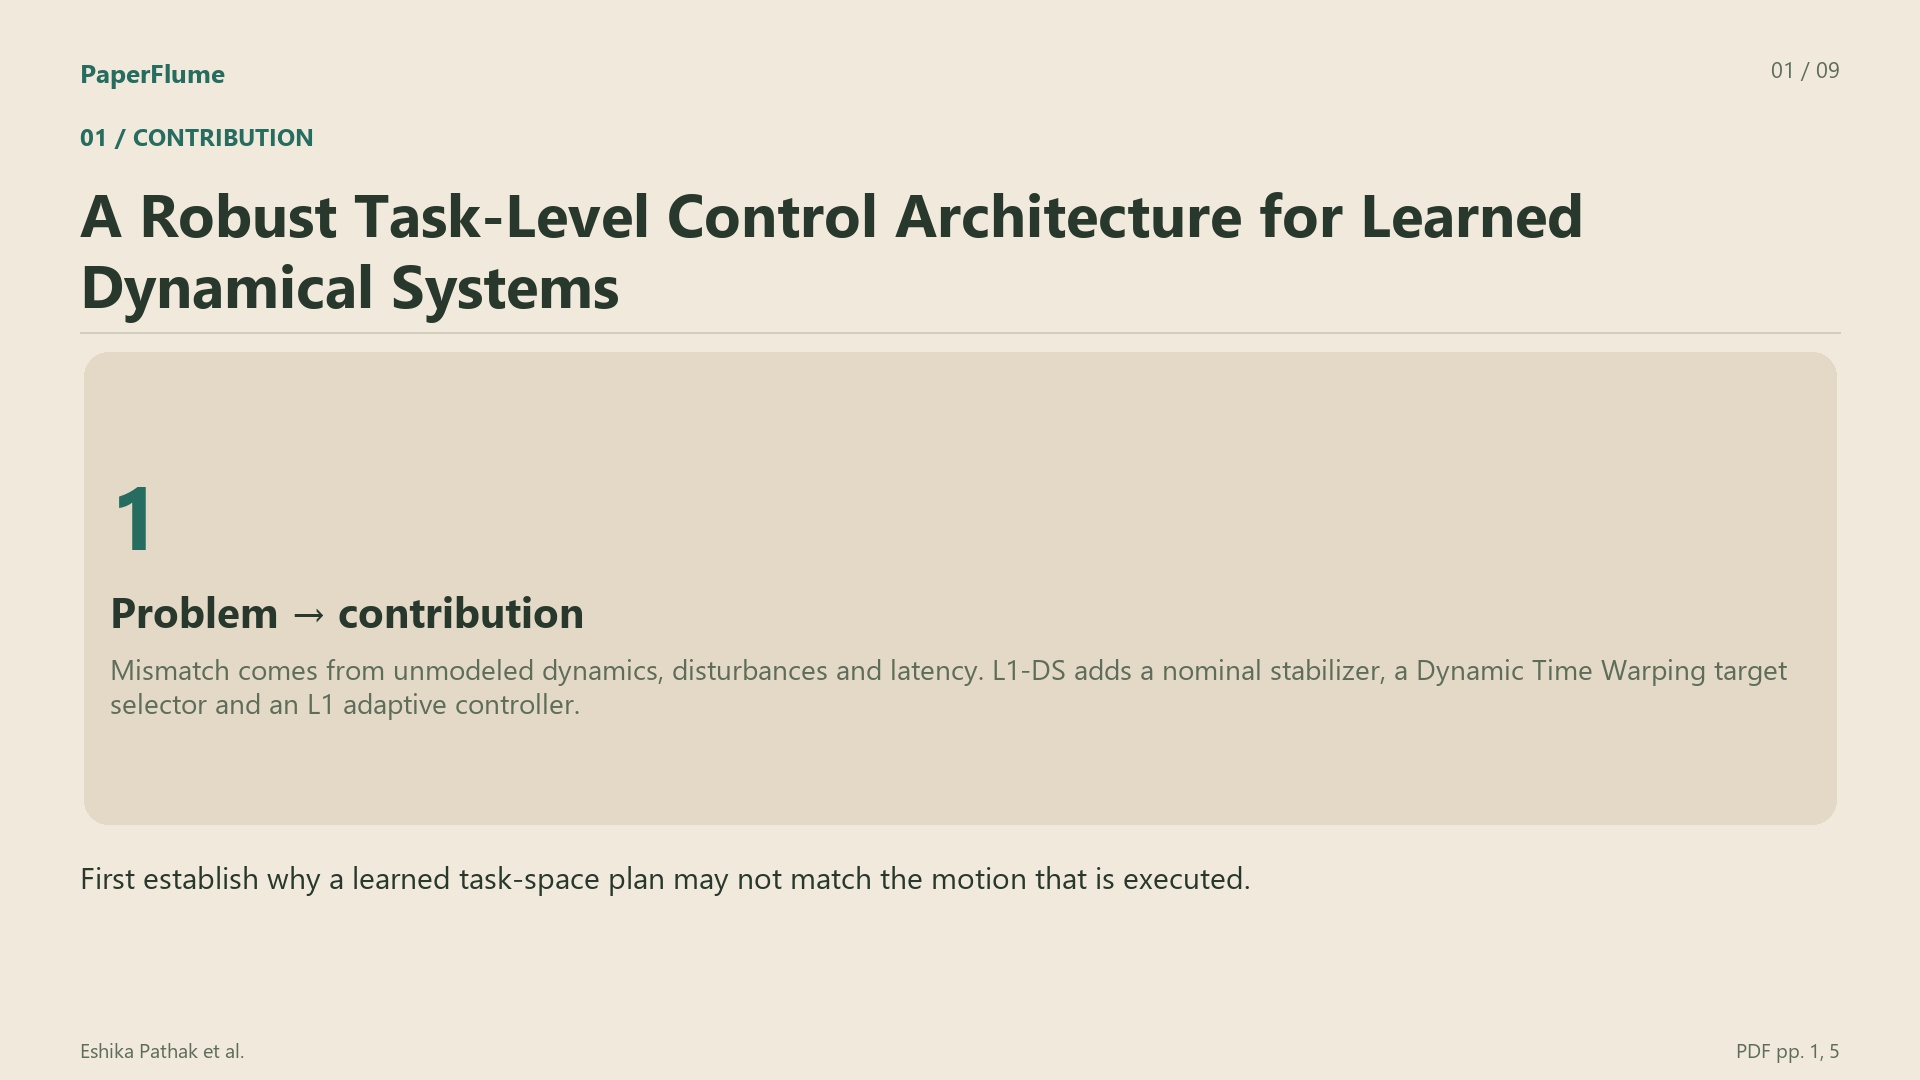 7:38
A Robust Task-Level Control Architecture for Learned Dynamical Systems
shares Learning from demonstration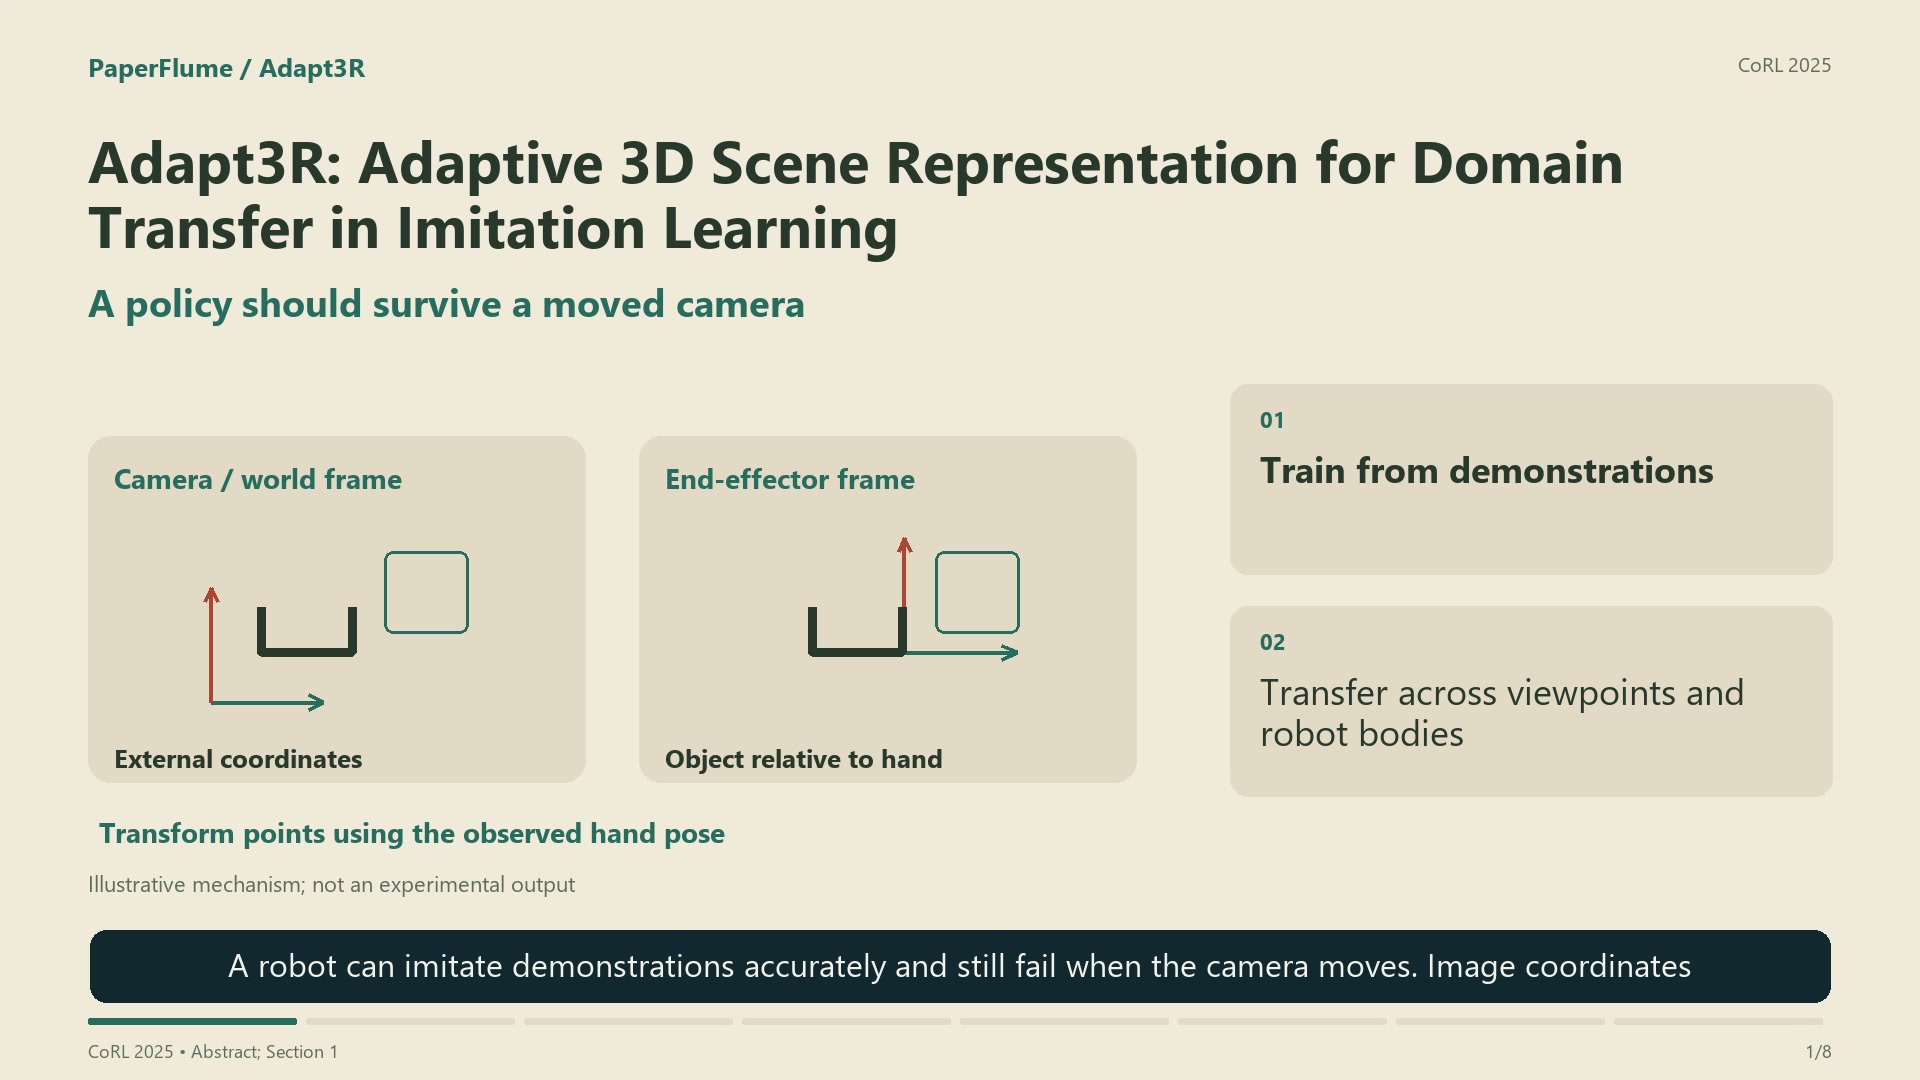 5:36
Adapt3R: Adaptive 3D Scene Representation for Domain Transfer in Imitation Learning
shares Learning from demonstrationShort cuts
 0:46
Active Constraint Learning in High Dimensions from Demonstrations
shares Trajectory optimisation 0:51
A Robust Task-Level Control Architecture for Learned Dynamical Systems
shares Learning from demonstration 0:50