Next
Papers near this one.
Walkthroughs
 7:52
GCIMOPT: Learning efficient goal-conditioned policies by imitating optimal trajectories
shares Trajectory optimisation 6:37
Active Constraint Learning in High Dimensions from Demonstrations
shares Trajectory optimisation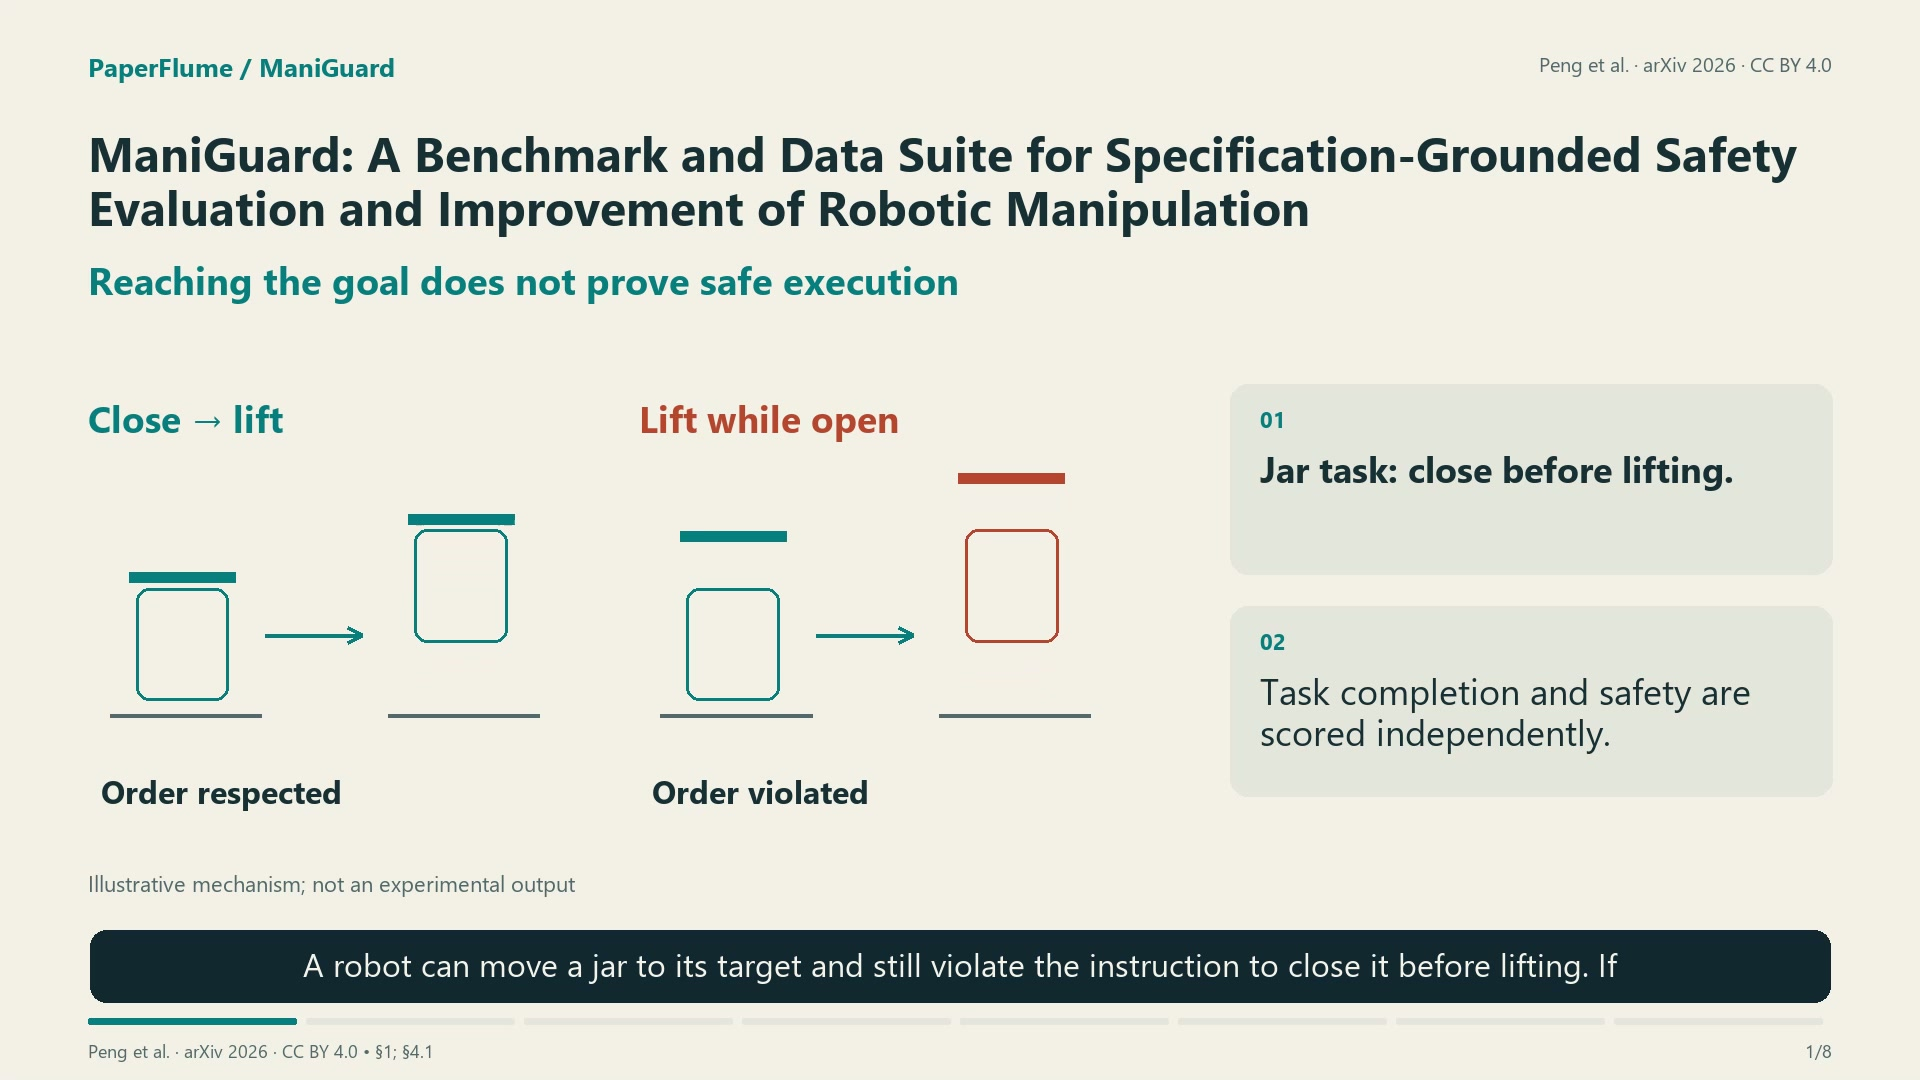 6:45
ManiGuard: A Benchmark and Data Suite for Specification-Grounded Safety Evaluation and Improvement of Robotic Manipulation
2608.17386
shares VLA models
Short cuts
 0:50
GCIMOPT: Learning efficient goal-conditioned policies by imitating optimal trajectories
shares Trajectory optimisation 0:46
Active Constraint Learning in High Dimensions from Demonstrations
shares Trajectory optimisation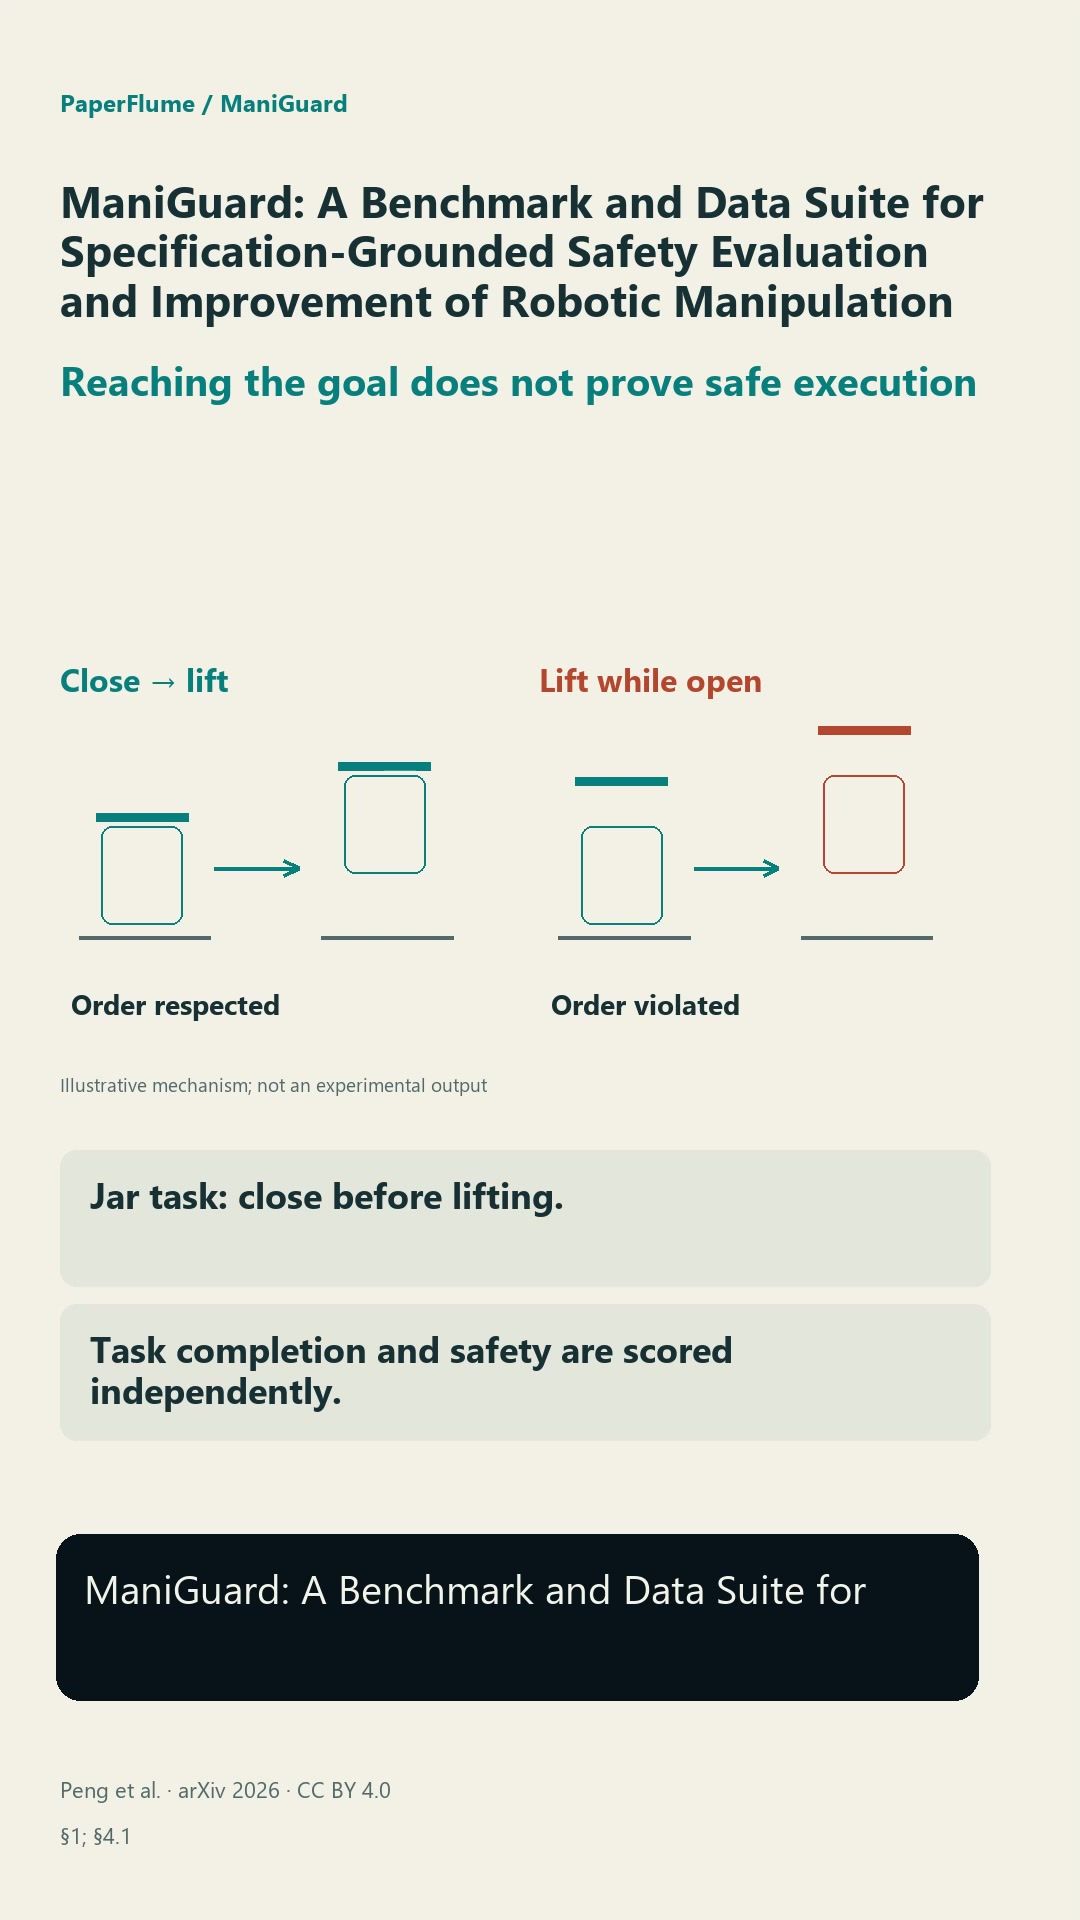 0:57
ManiGuard: A Benchmark and Data Suite for Specification-Grounded Safety Evaluation and Improvement of Robotic Manipulation
2608.17386
shares VLA models