Next
Papers near this one.
Walkthroughs
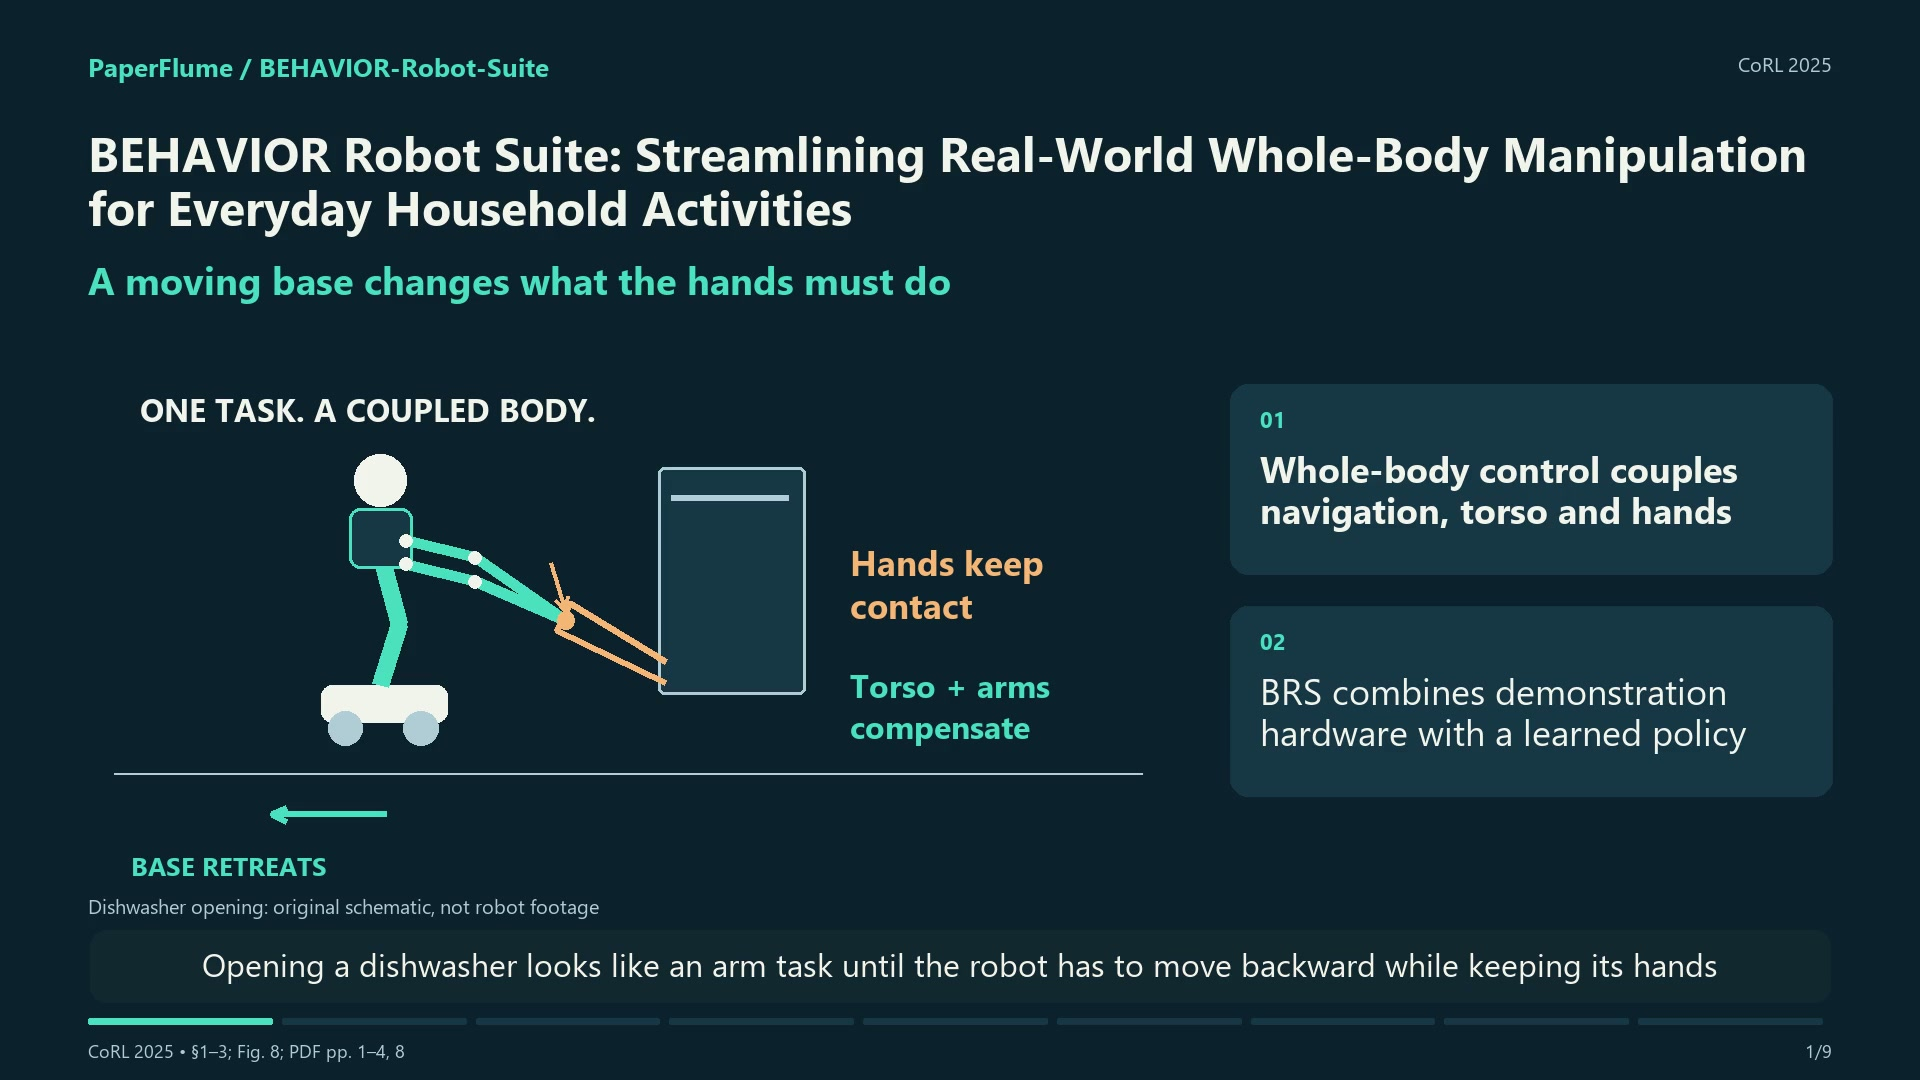 7:39
BEHAVIOR Robot Suite: Streamlining Real-World Whole-Body Manipulation for Everyday Household Activities
shares Mobile manipulation 7:37
Versatile Loco-Manipulation through Flexible Interlimb Coordination
shares Mobile manipulation 5:41
Learning to Act Through Contact: A Unified View of Multi-Task Robot Learning
shares Mobile manipulationShort cuts
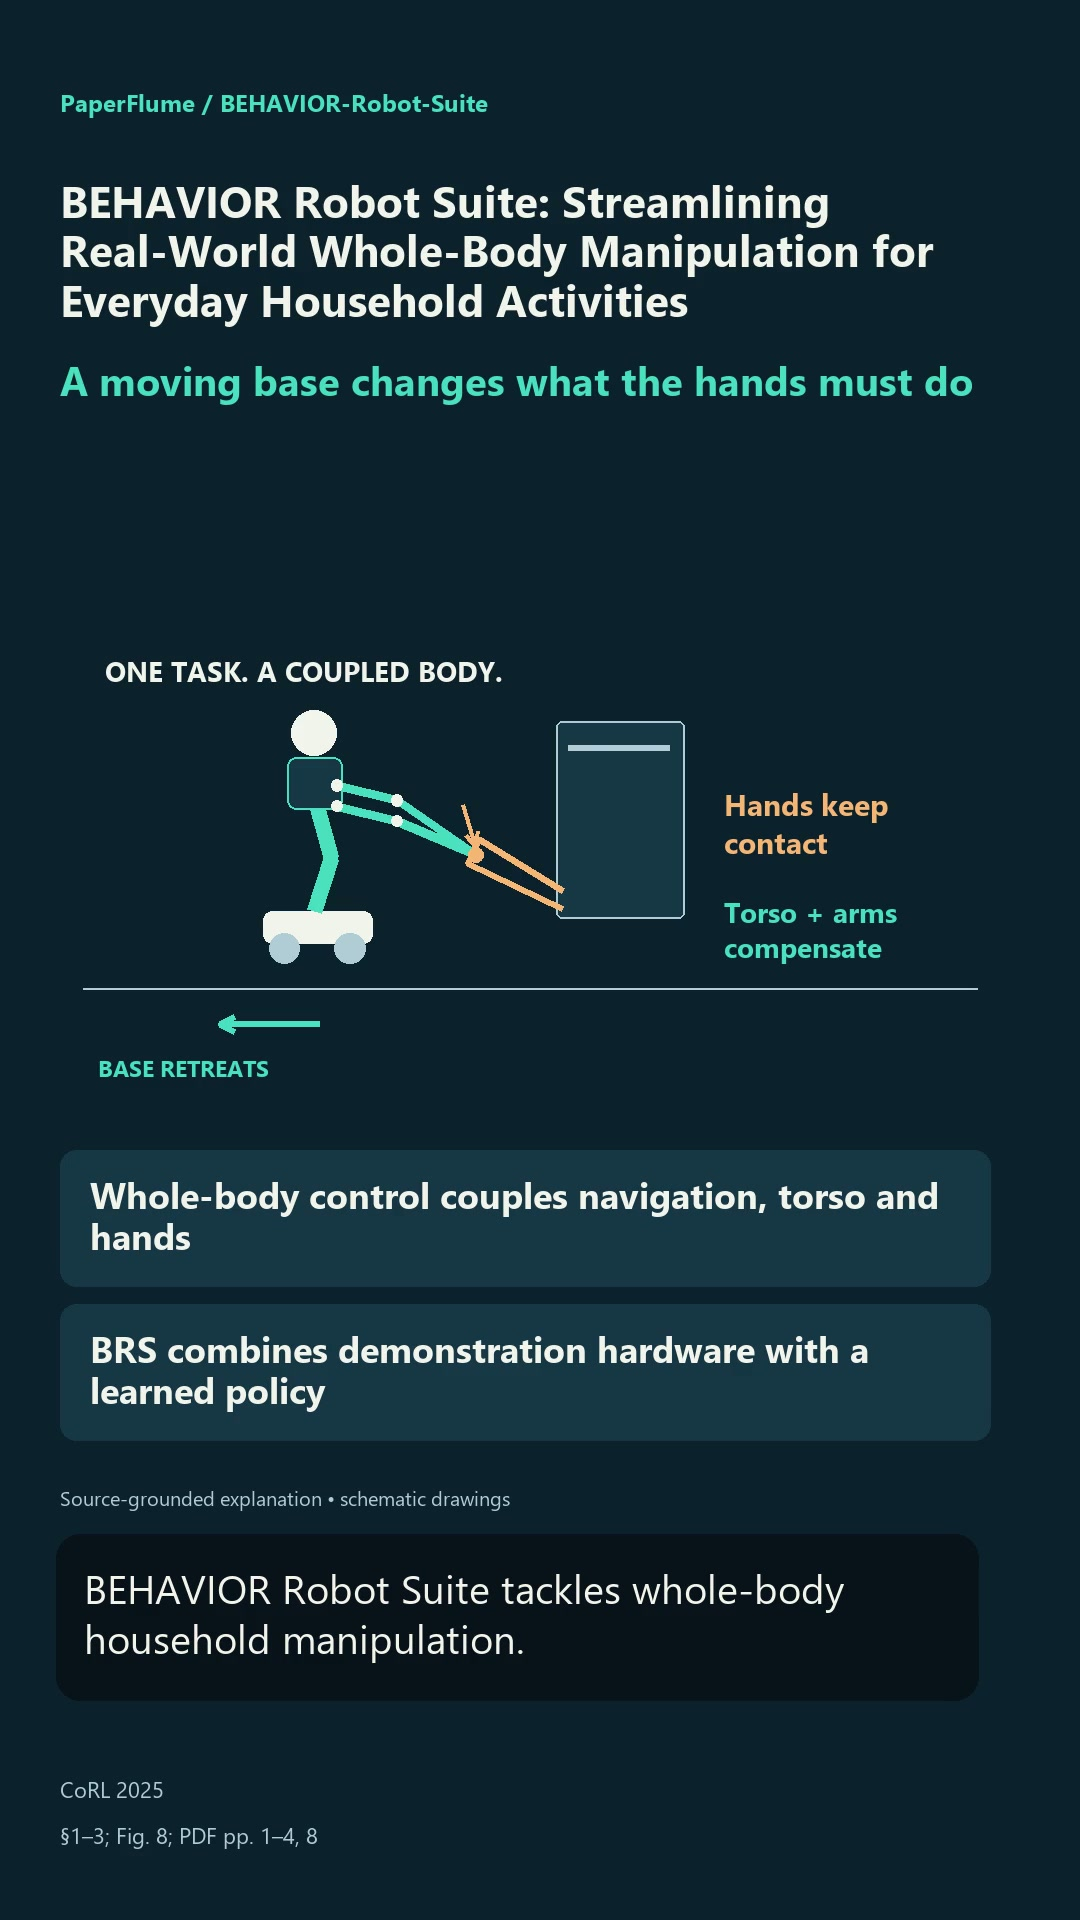 1:00
BEHAVIOR Robot Suite: Streamlining Real-World Whole-Body Manipulation for Everyday Household Activities
shares Mobile manipulation 0:54
Versatile Loco-Manipulation through Flexible Interlimb Coordination
shares Mobile manipulation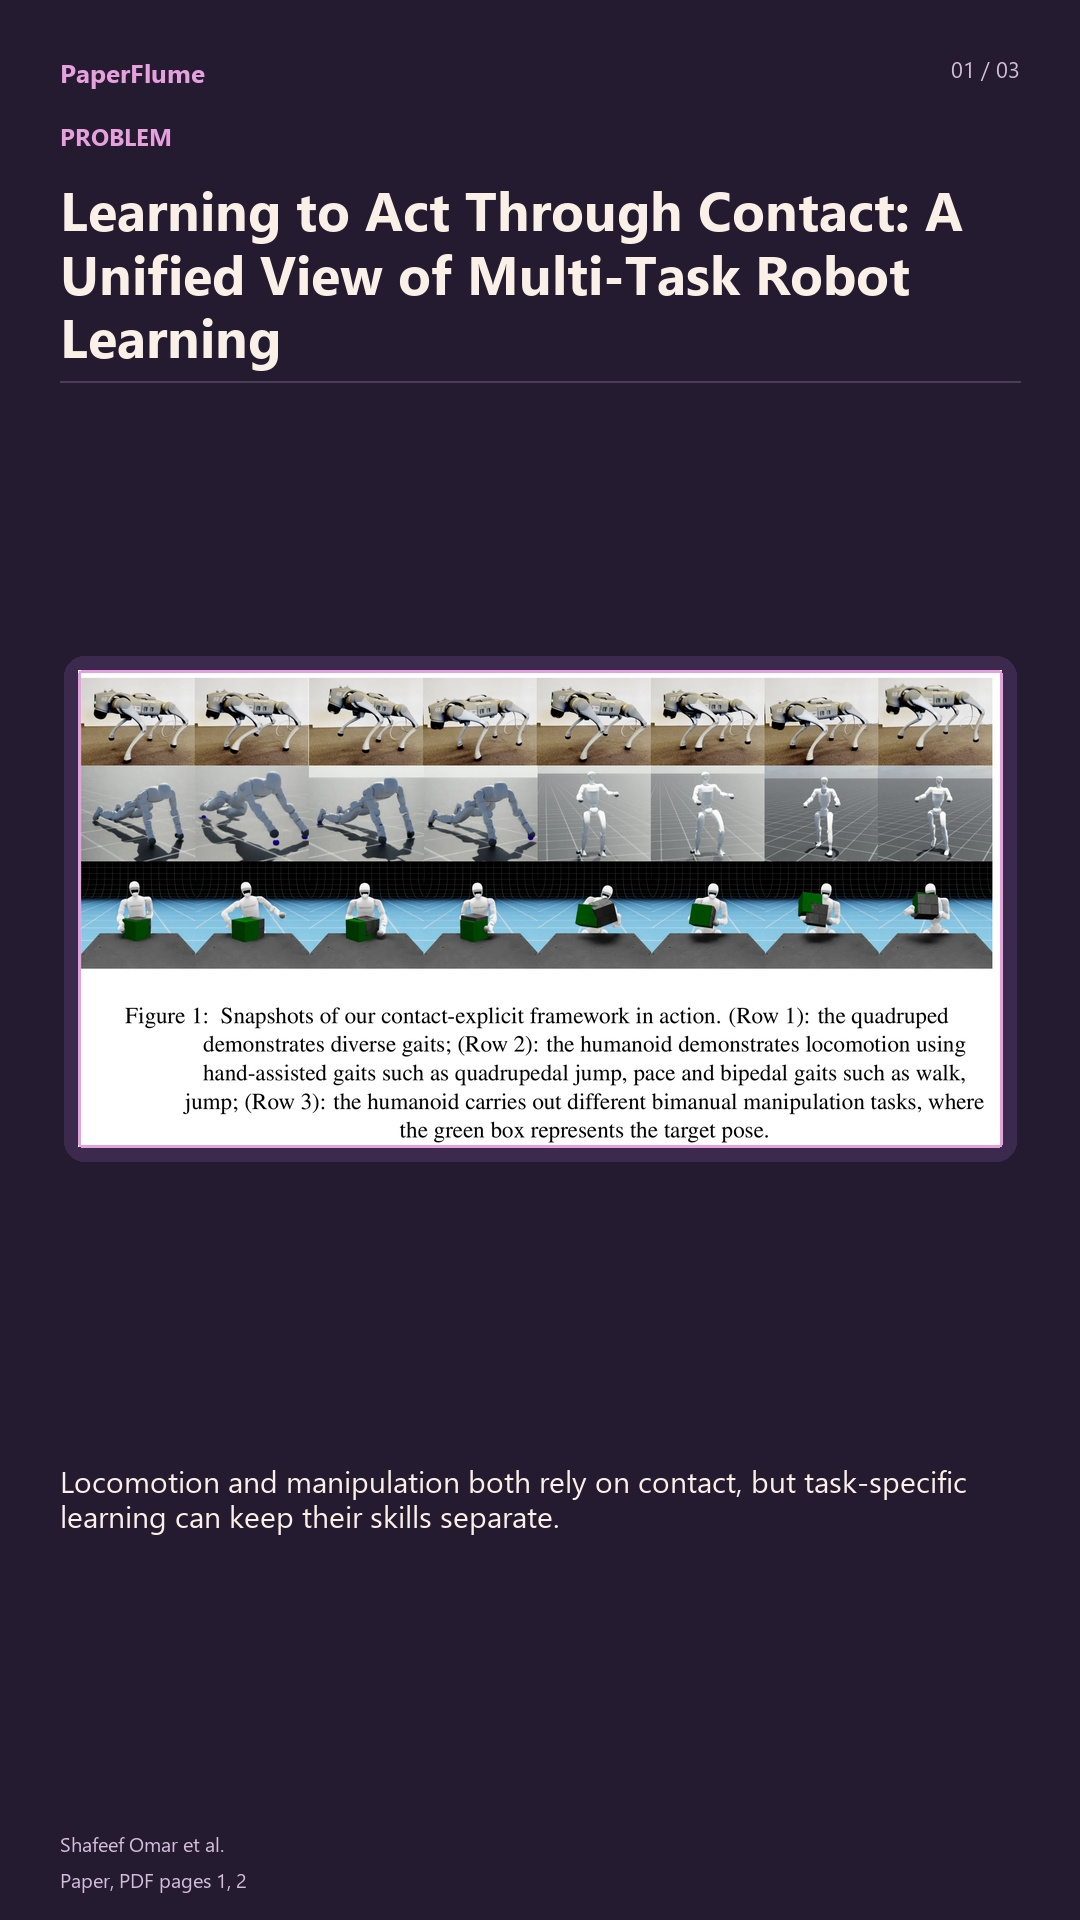 0:55