Next
Papers near this one.
Walkthroughs
 7:35
Learning to Plan, Planning to Learn: Adaptive Hierarchical RL-MPC for Sample-Efficient Decision Making
shares Model predictive control 5:27
Residual Neural Terminal Constraint for MPC-based Collision Avoidance in Dynamic Environments
shares Model predictive control 5:32
Multi-critic Learning for Whole-body End-effector Twist Tracking
shares RL for controlShort cuts
 0:56
Learning to Plan, Planning to Learn: Adaptive Hierarchical RL-MPC for Sample-Efficient Decision Making
shares Model predictive control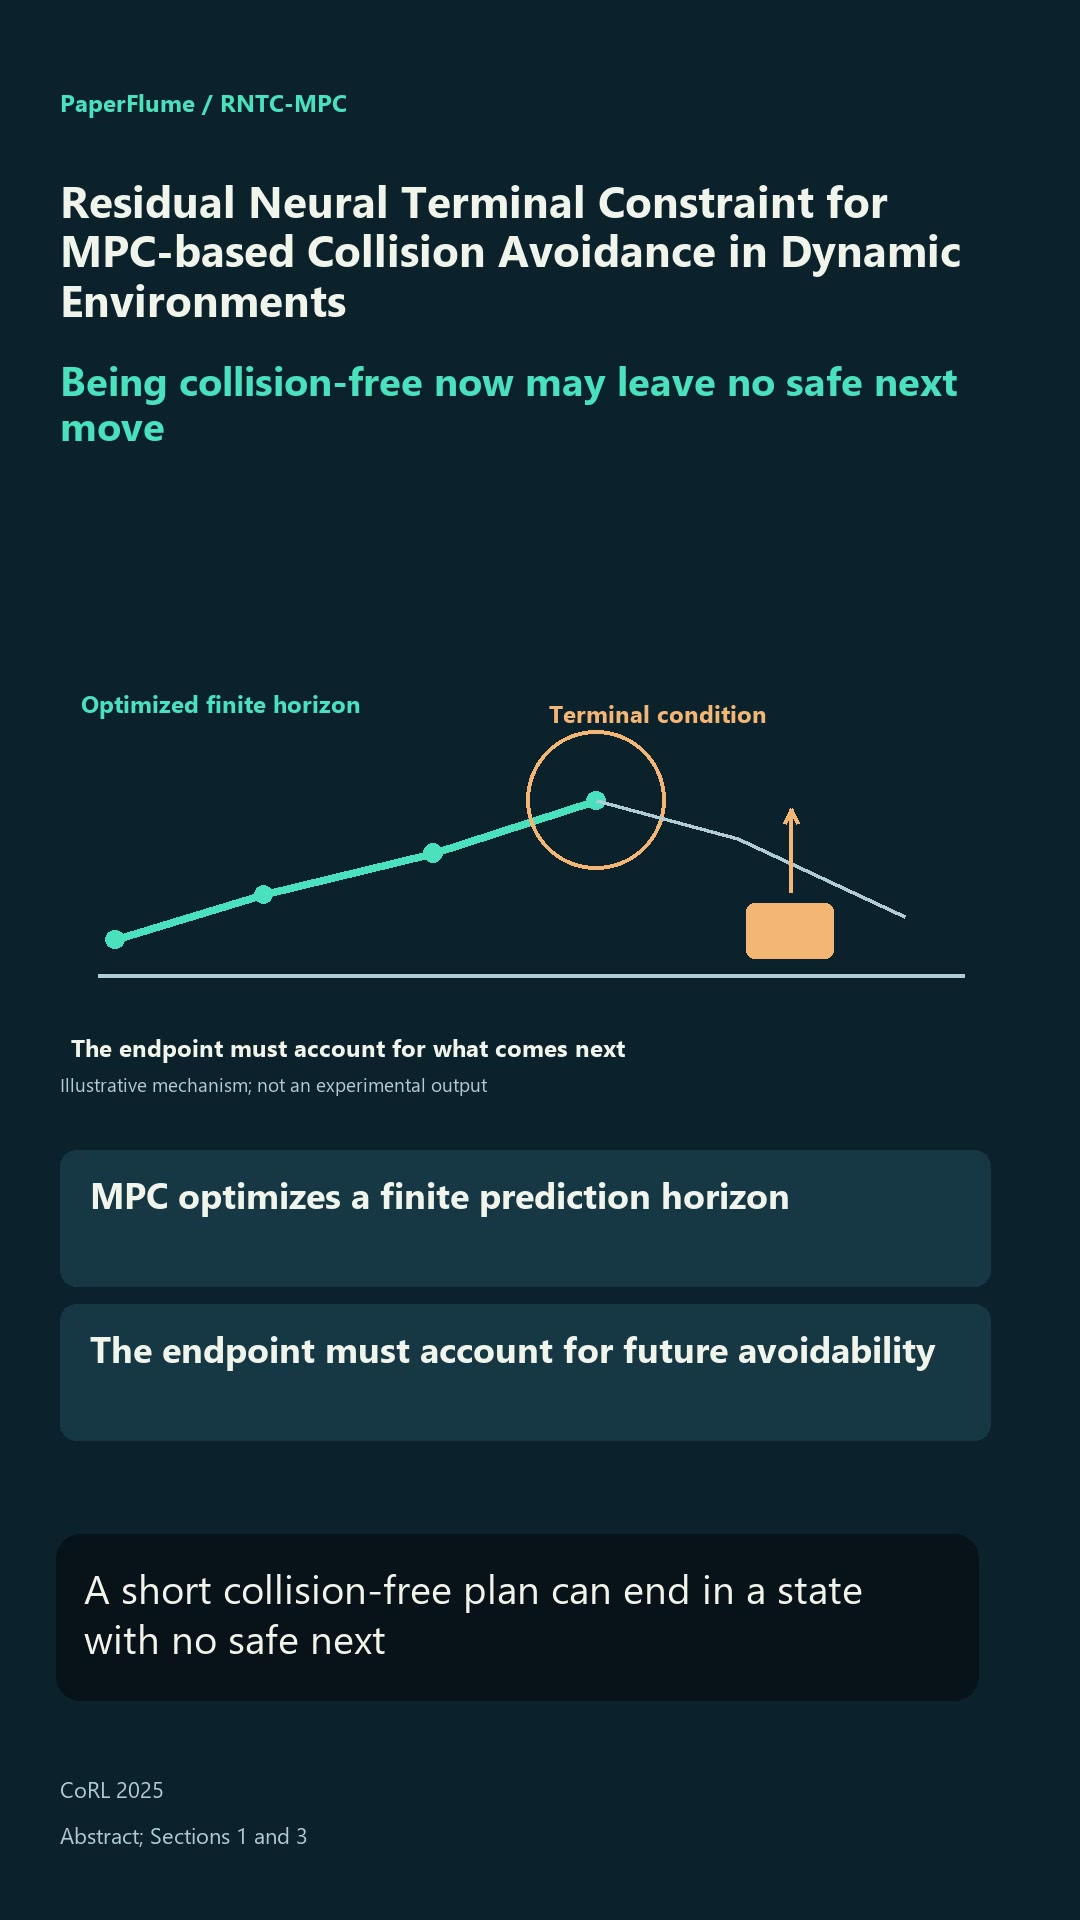 0:48
Residual Neural Terminal Constraint for MPC-based Collision Avoidance in Dynamic Environments
shares Model predictive control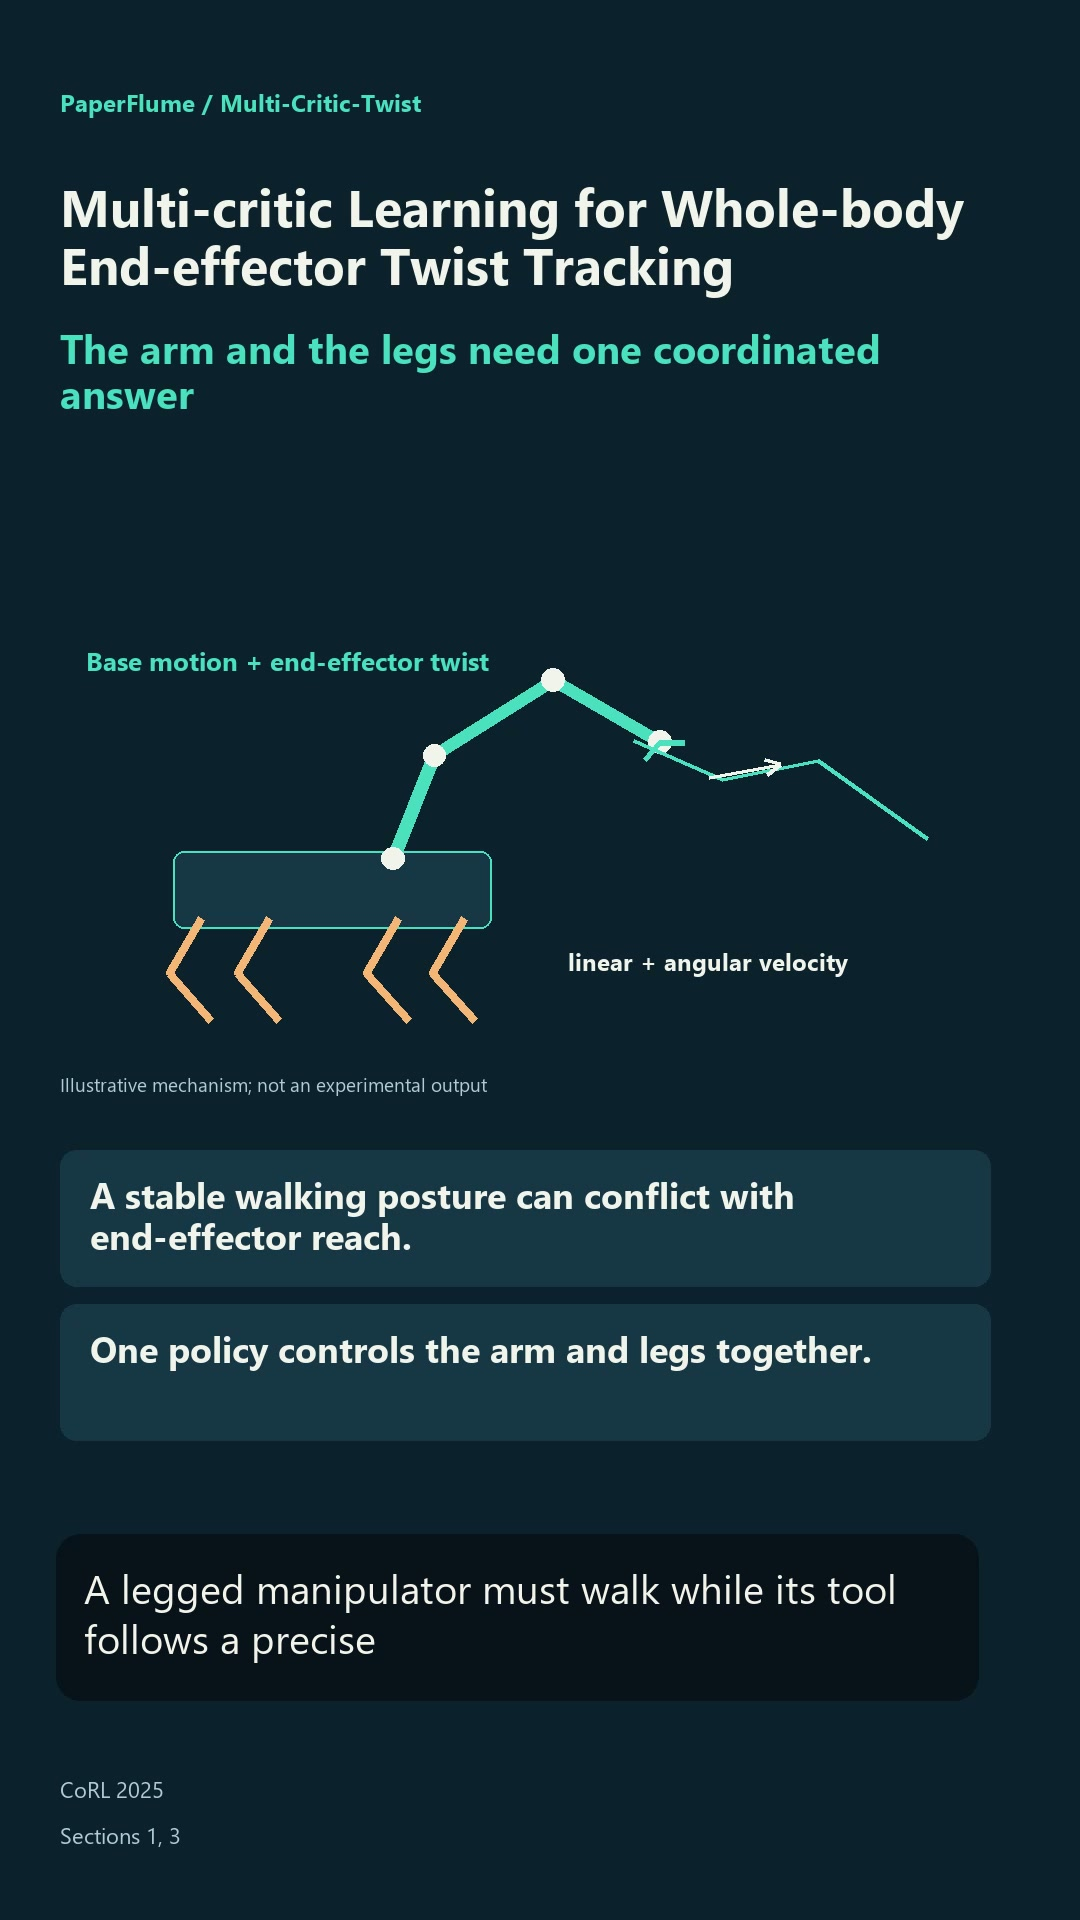 0:59