Next
Papers near this one.
Walkthroughs
 6:39
Provably Safe Stein Variational Clarity-Aware Informative Planning
shares Trajectory optimisation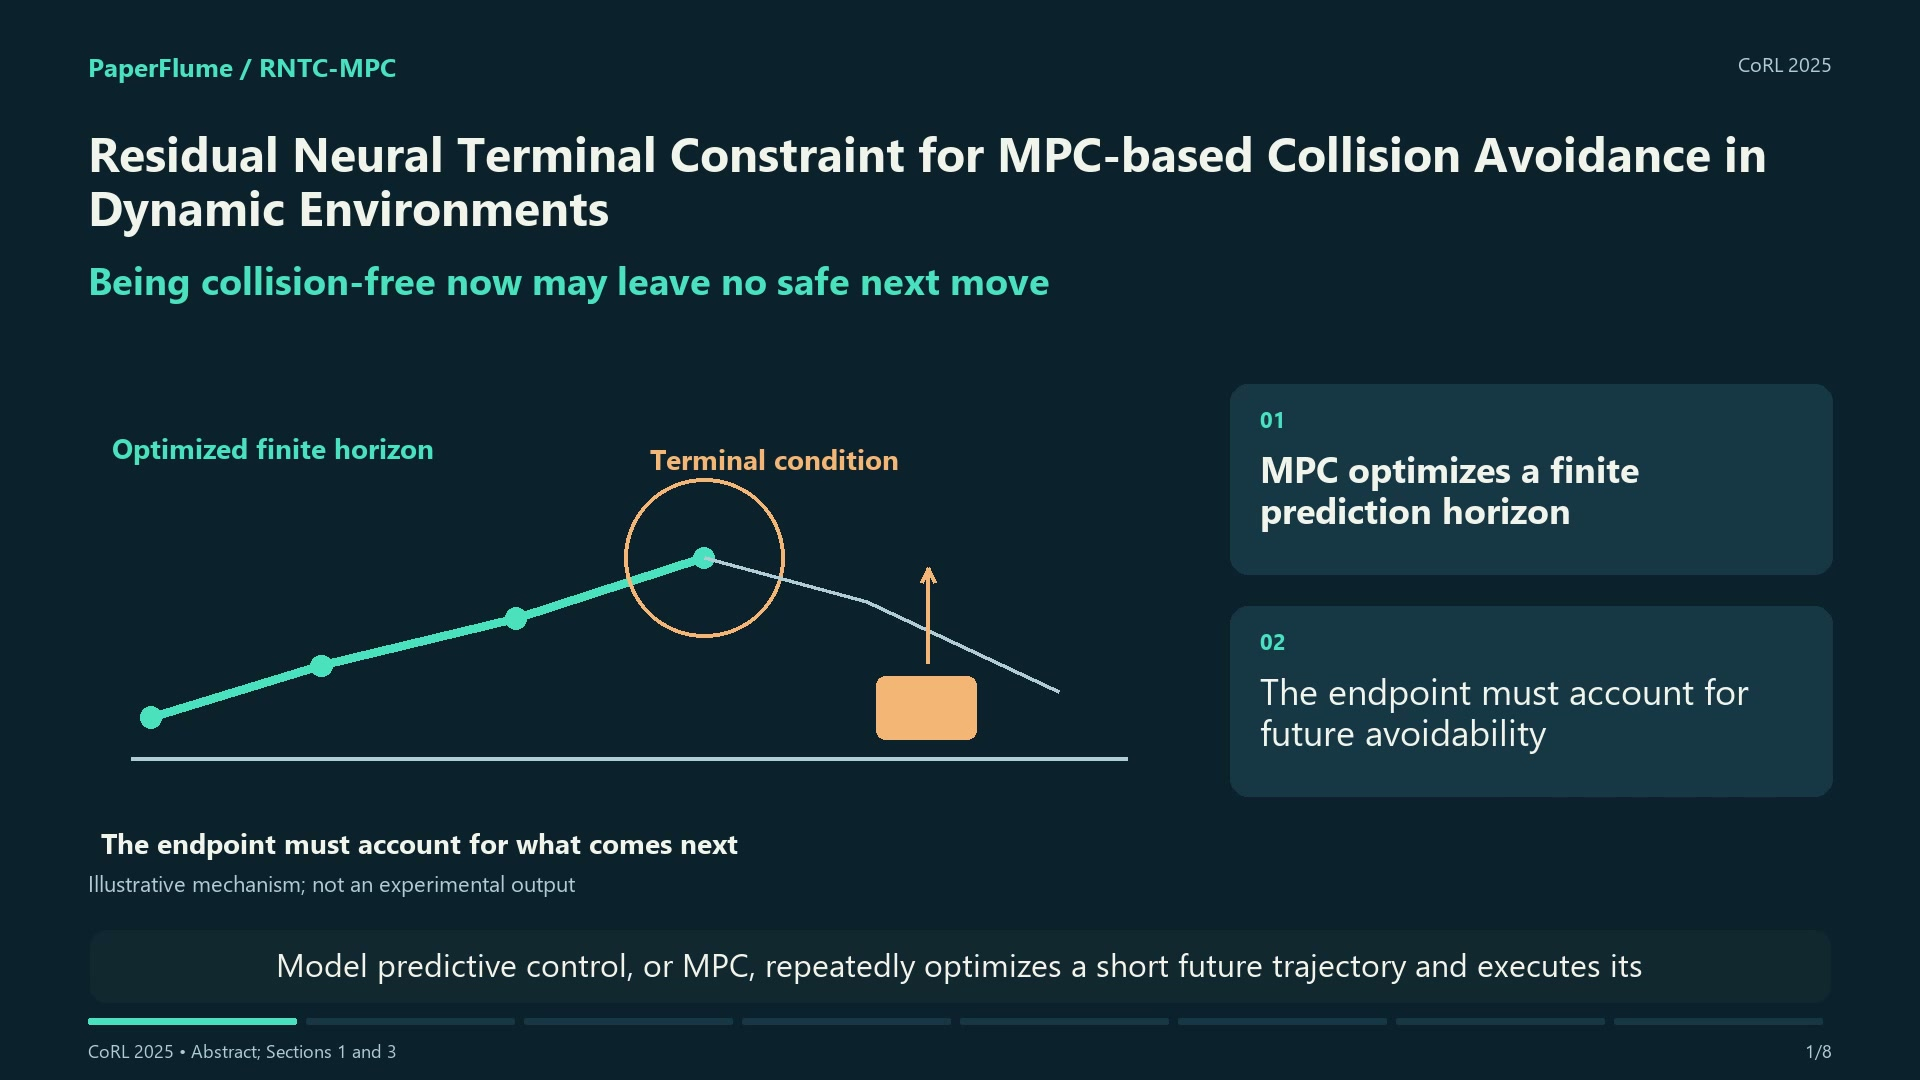 5:27
Residual Neural Terminal Constraint for MPC-based Collision Avoidance in Dynamic Environments
shares Model predictive control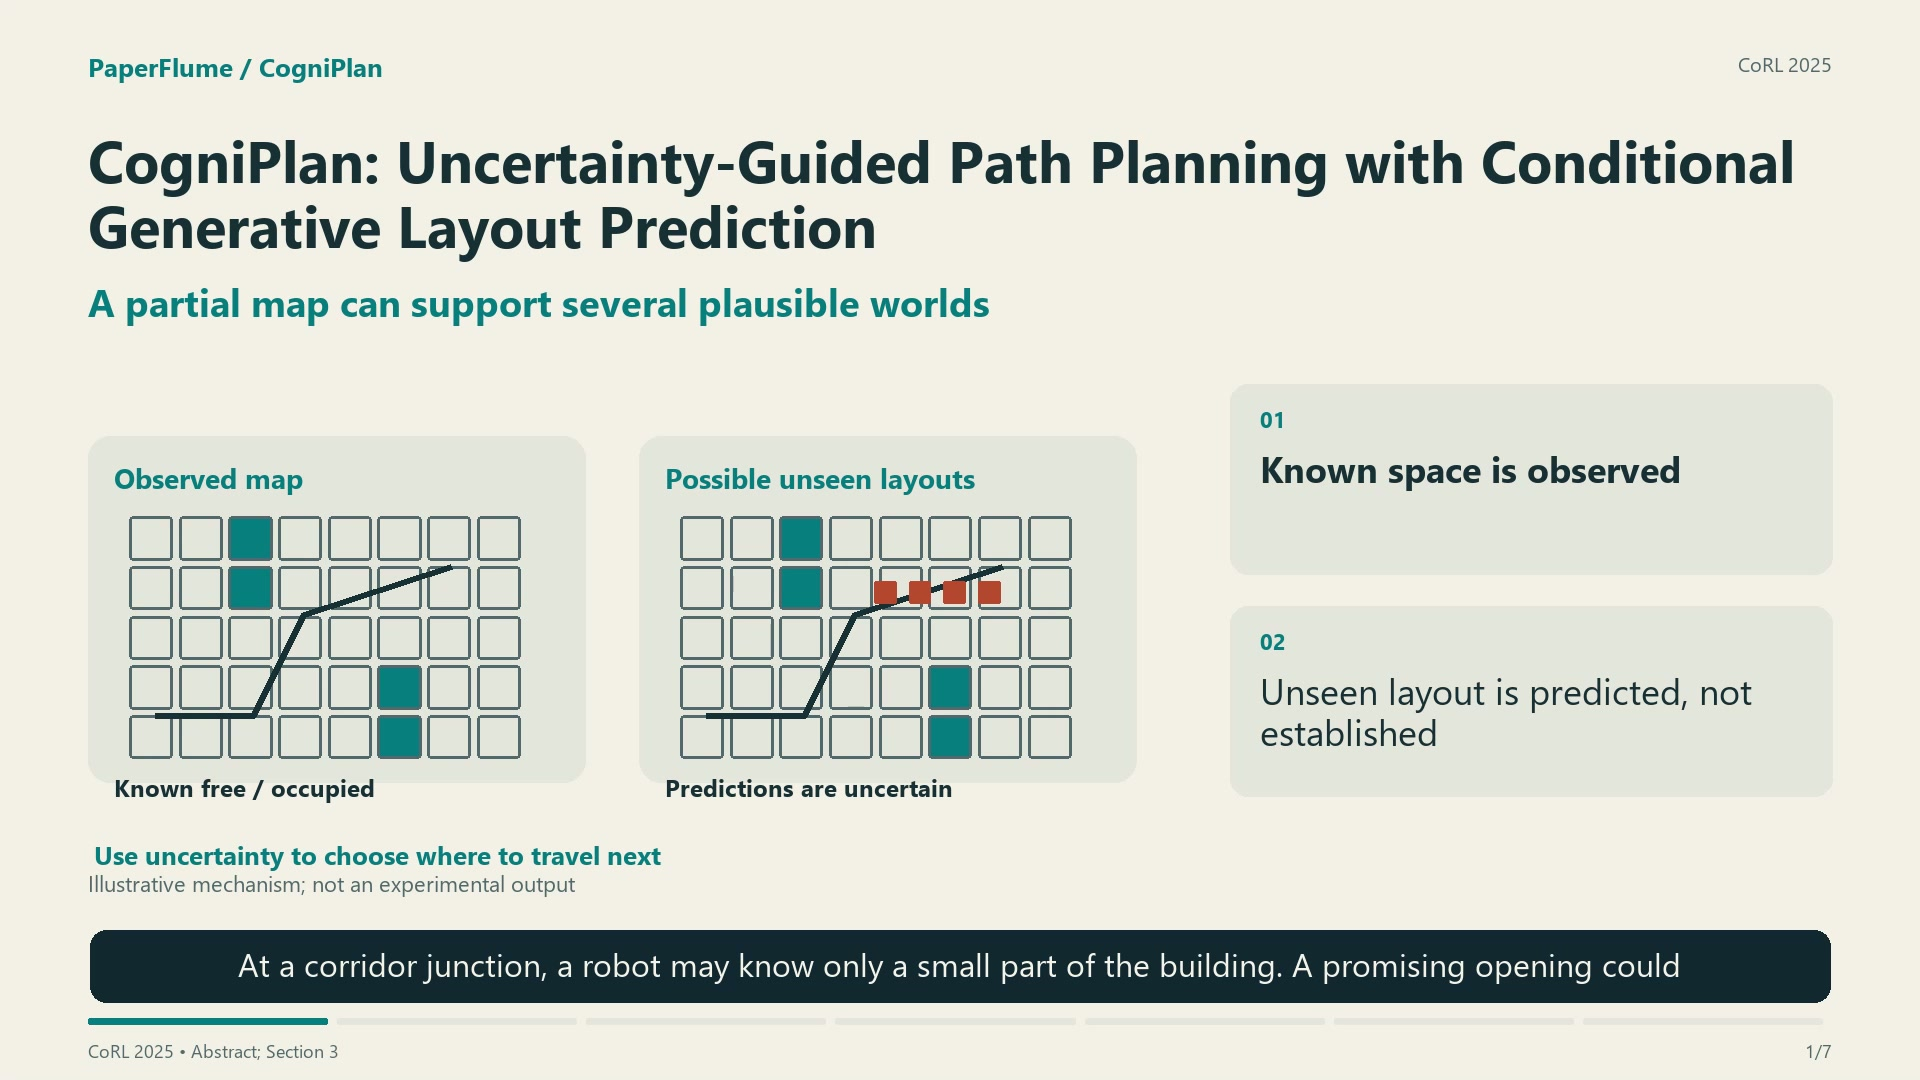 5:24
CogniPlan: Uncertainty-Guided Path Planning with Conditional Generative Layout Prediction
shares Informative path planningShort cuts
 0:47
Provably Safe Stein Variational Clarity-Aware Informative Planning
shares Trajectory optimisation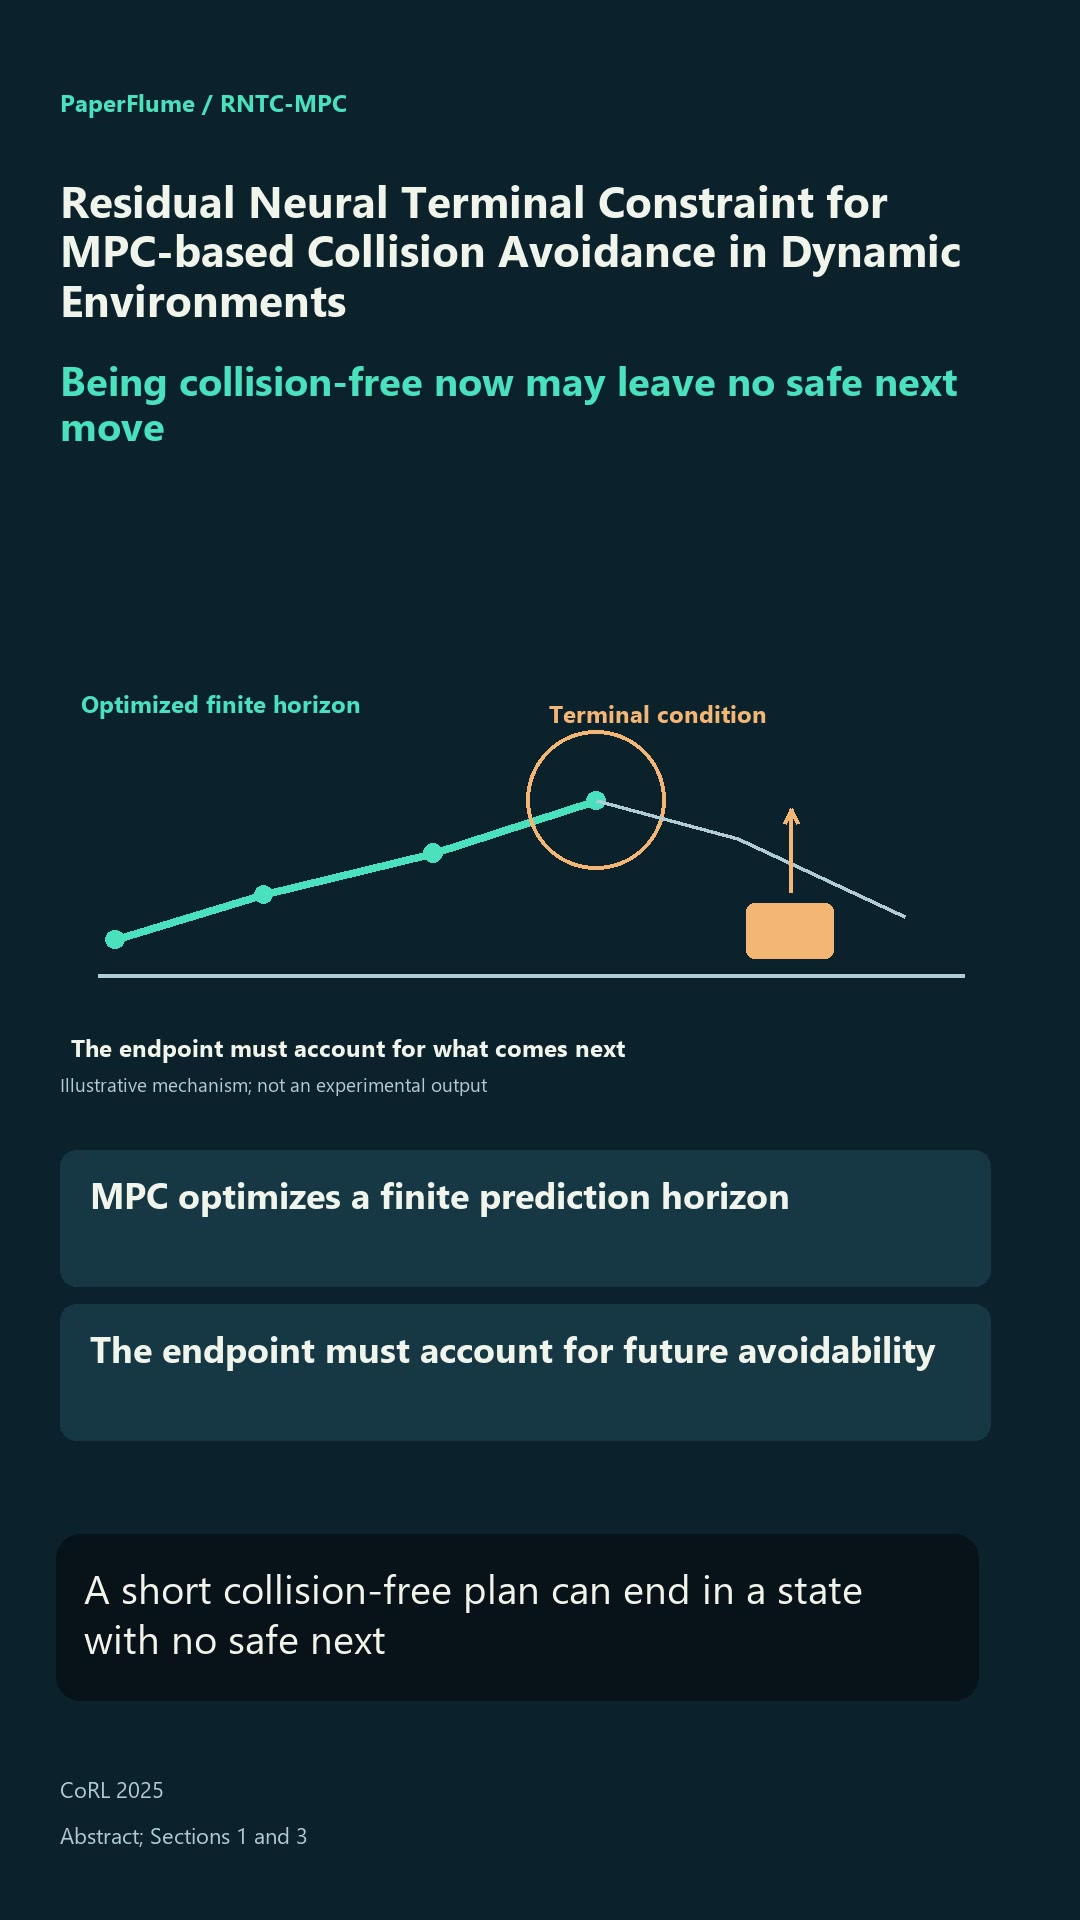 0:48
Residual Neural Terminal Constraint for MPC-based Collision Avoidance in Dynamic Environments
shares Model predictive control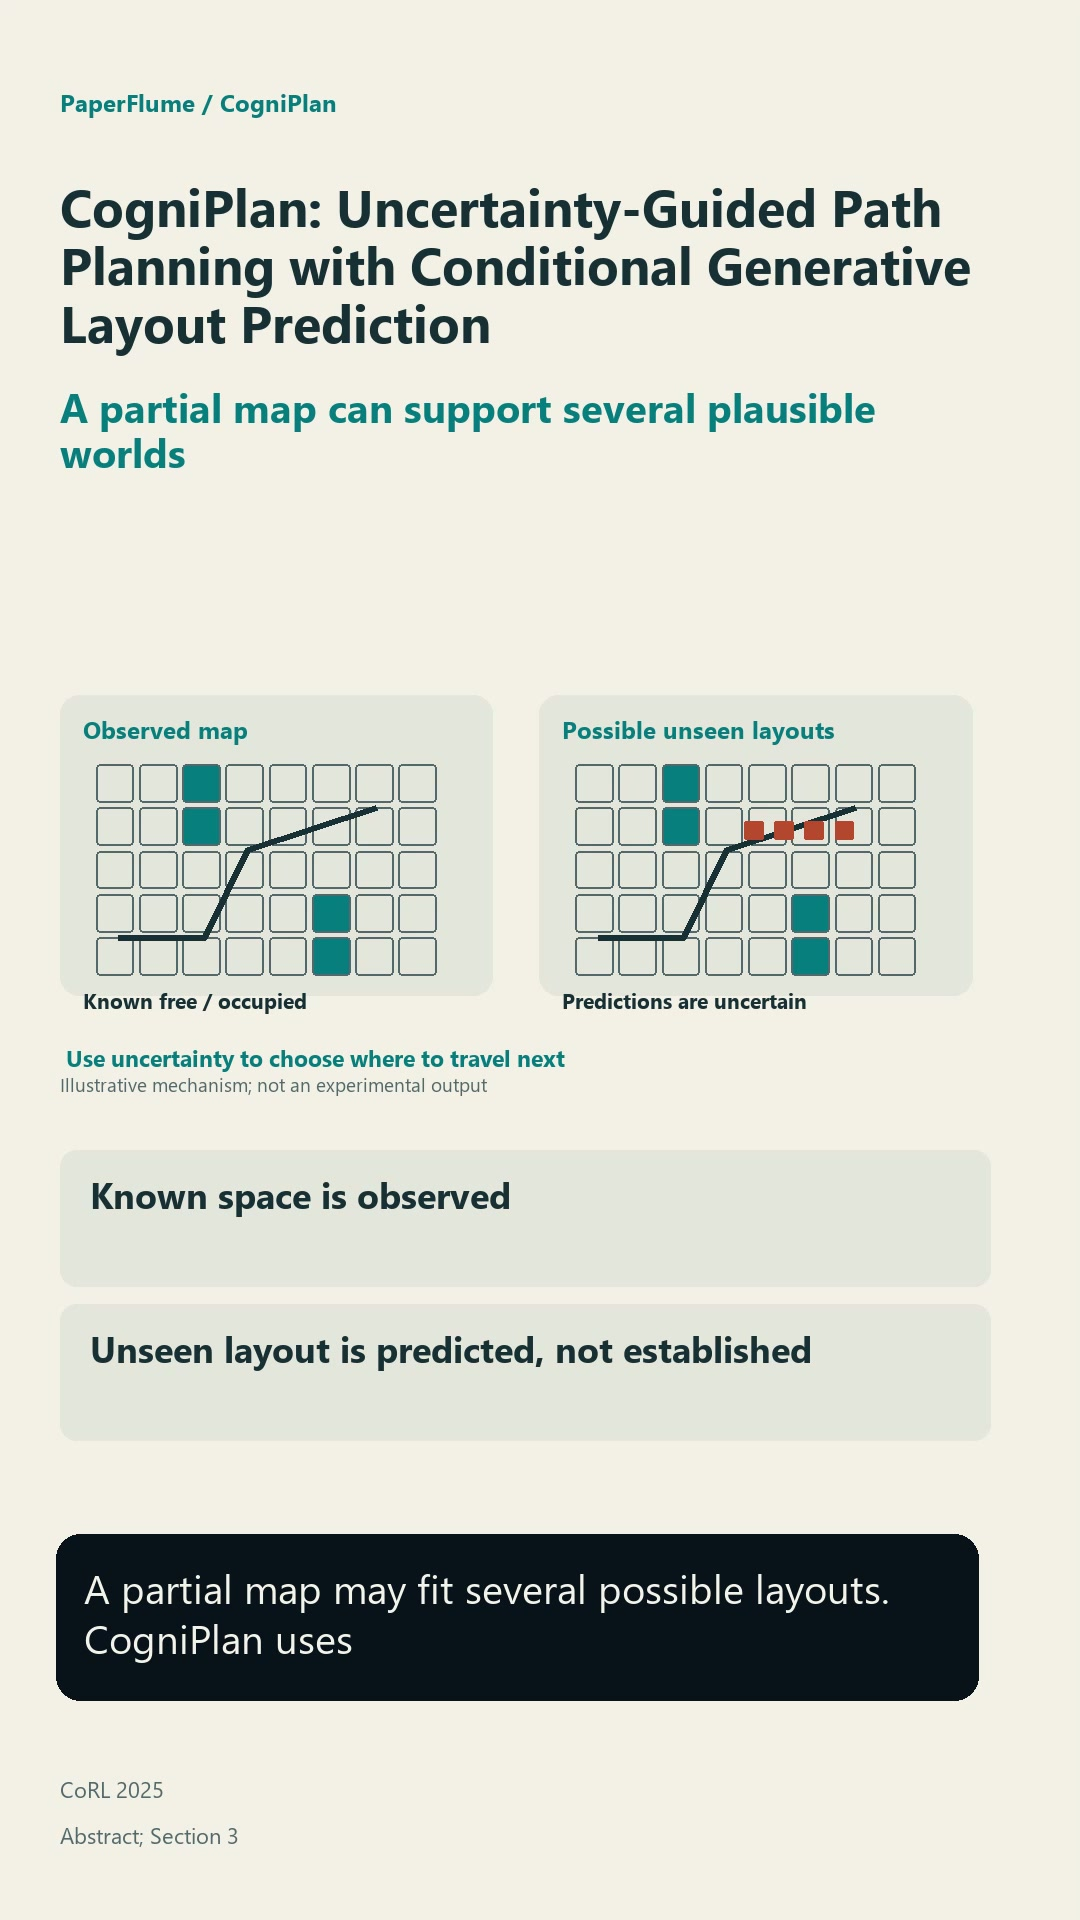 0:55