Next
Papers near this one.
Walkthroughs
 6:45
ManiGuard: A Benchmark and Data Suite for Specification-Grounded Safety Evaluation and Improvement of Robotic Manipulation
2608.17386
shares VLA models
 6:45
RHO: Your Coding Agent is Secretly a Roboticist
2606.16458
shares Multimodal LLMs
 6:42
FARM: Find Anything using Relational Spatial Memory
2606.15476
shares Open-vocabulary perception
Short cuts
 0:57
ManiGuard: A Benchmark and Data Suite for Specification-Grounded Safety Evaluation and Improvement of Robotic Manipulation
2608.17386
shares VLA models
 0:57
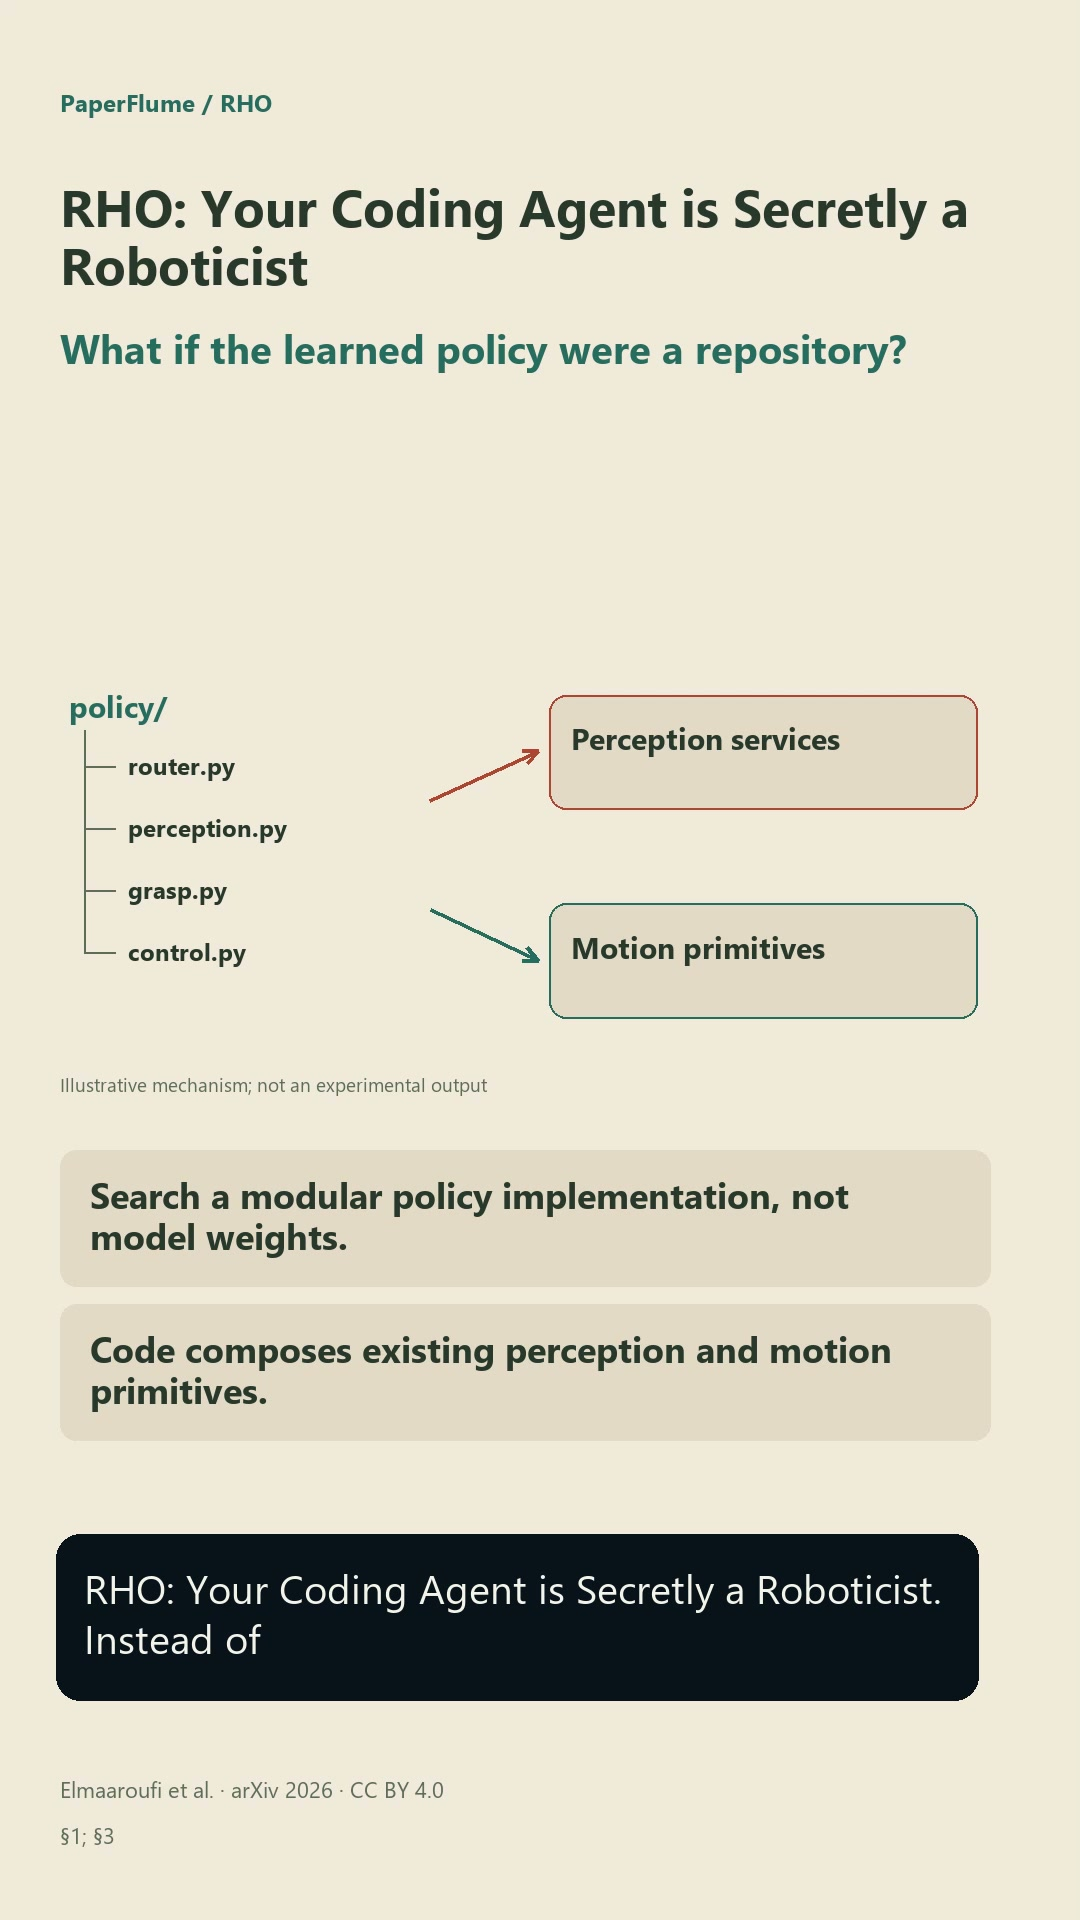
RHO: Your Coding Agent is Secretly a Roboticist
2606.16458
shares Multimodal LLMs
 0:52
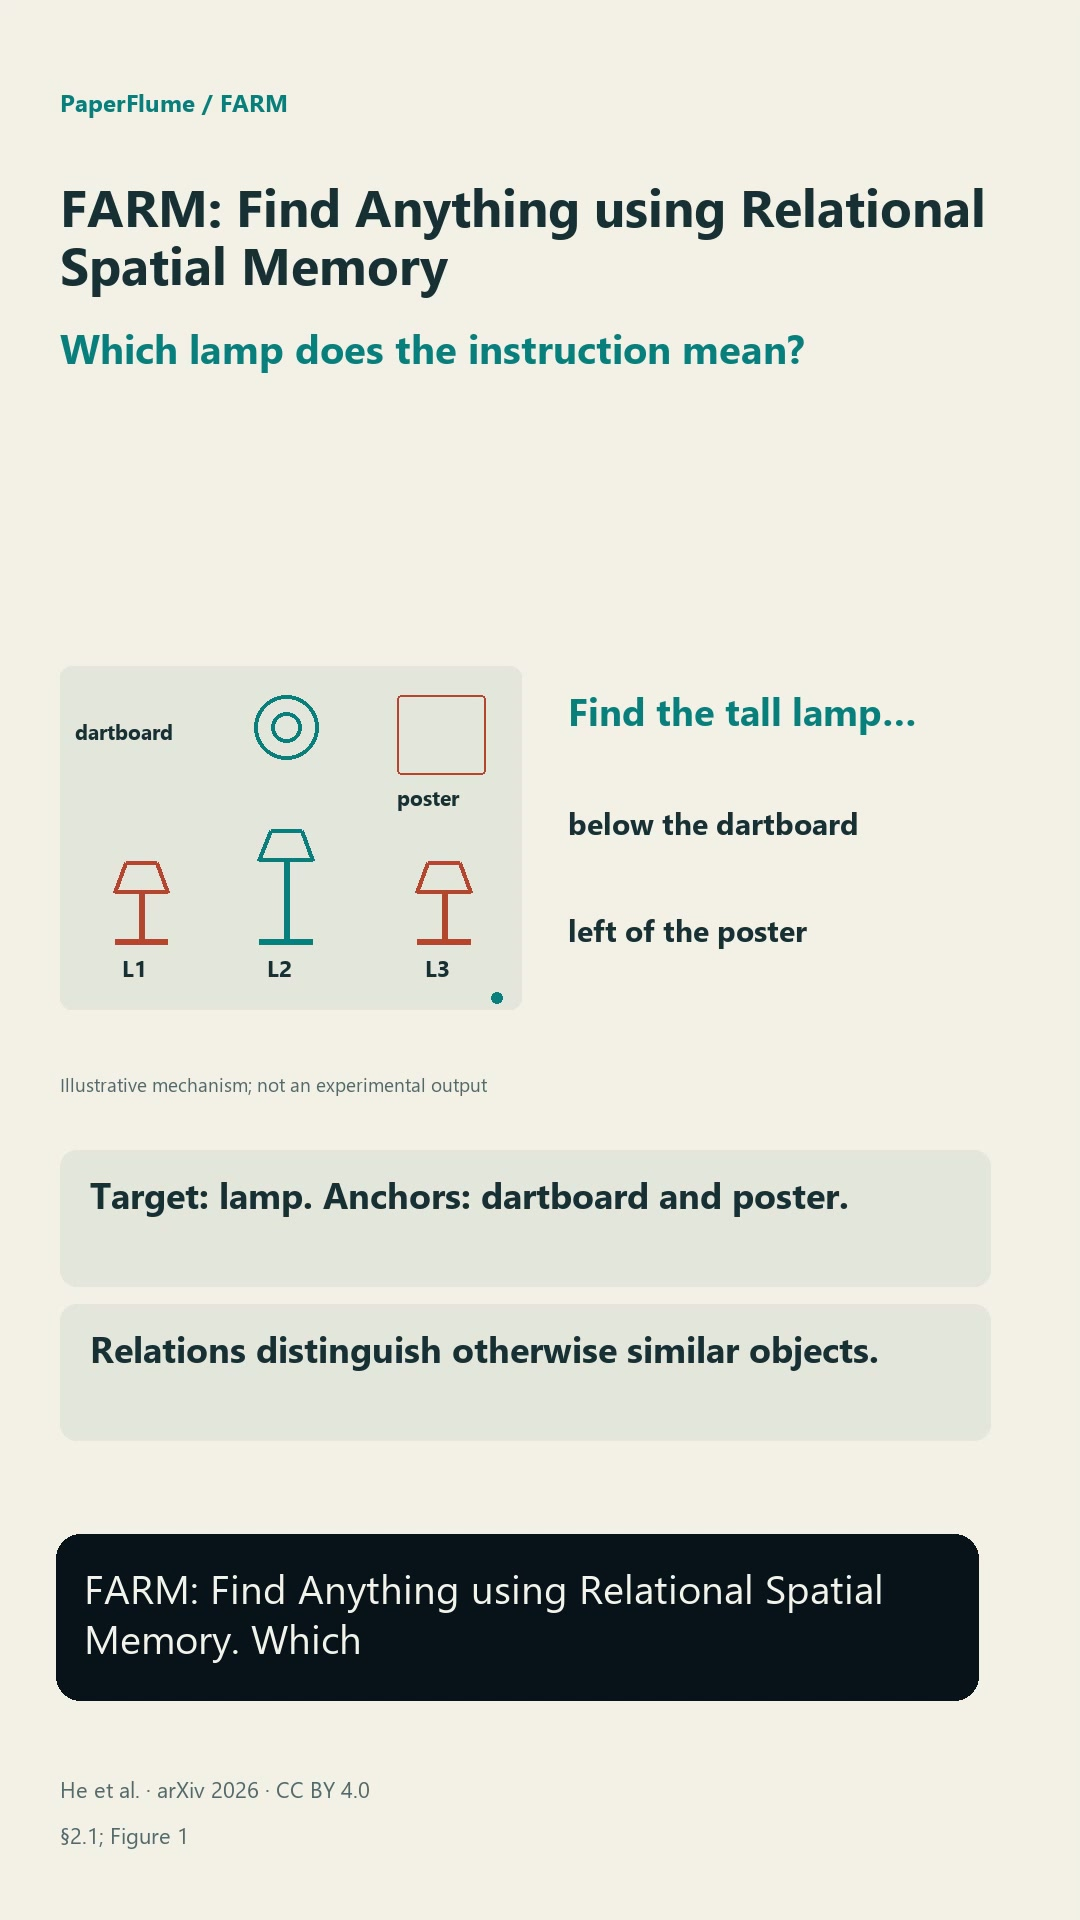
FARM: Find Anything using Relational Spatial Memory
2606.15476
shares Open-vocabulary perception